GIFs
Short loops of tactile sensing, manipulation, and robot learning.
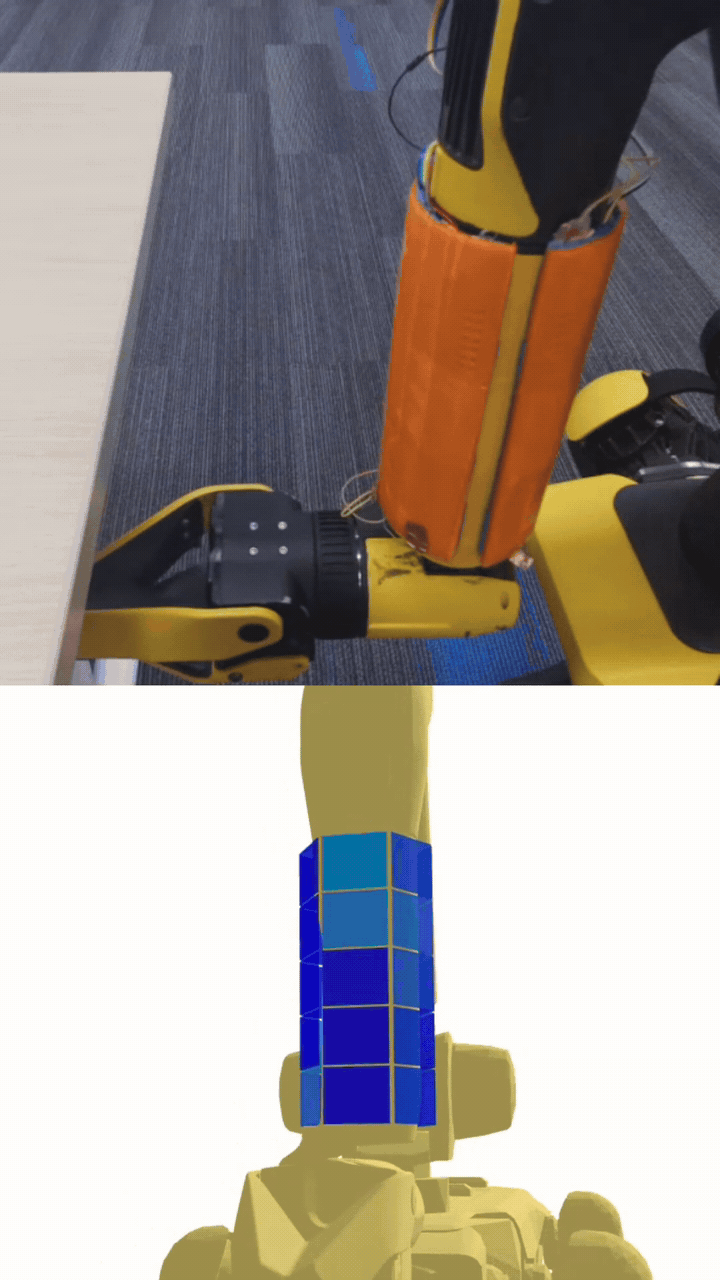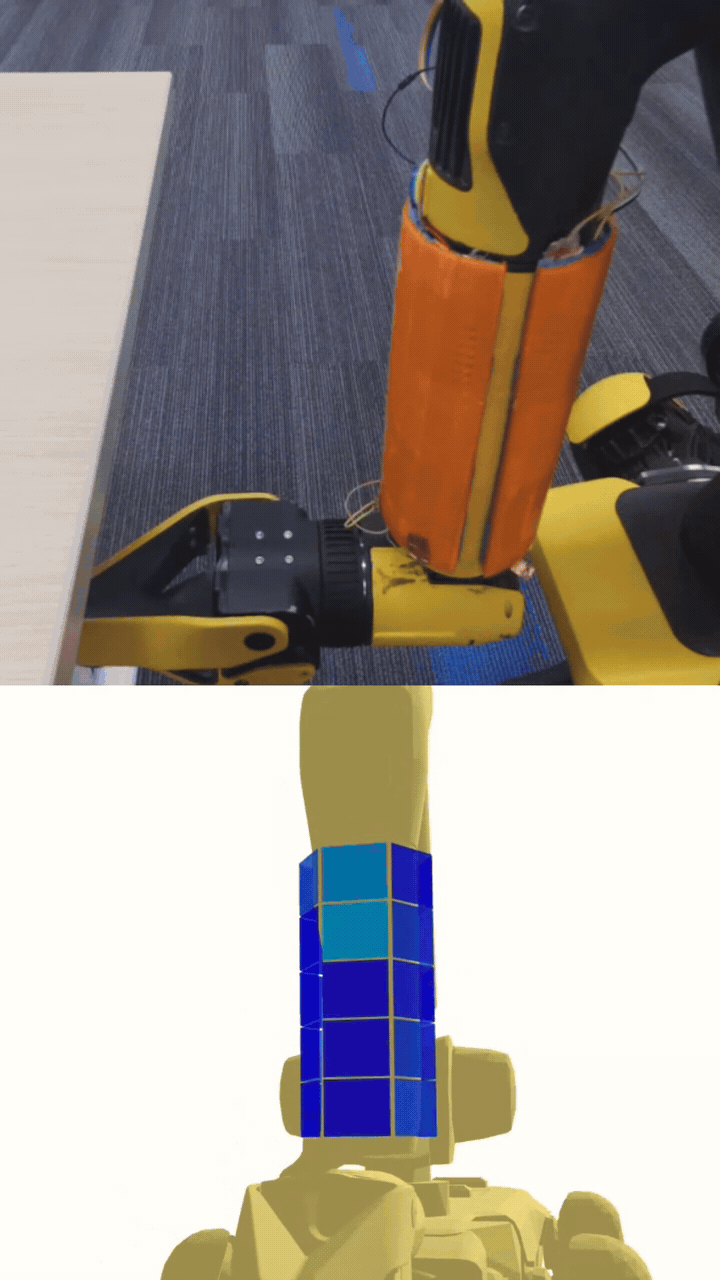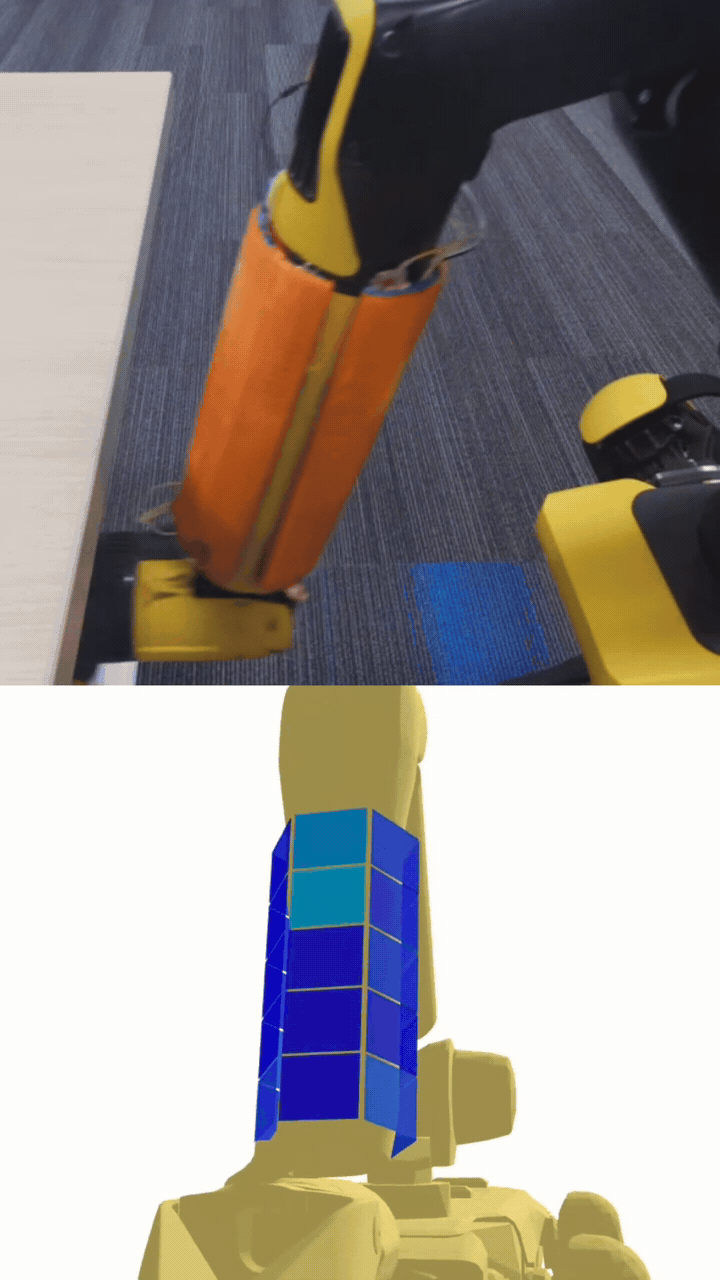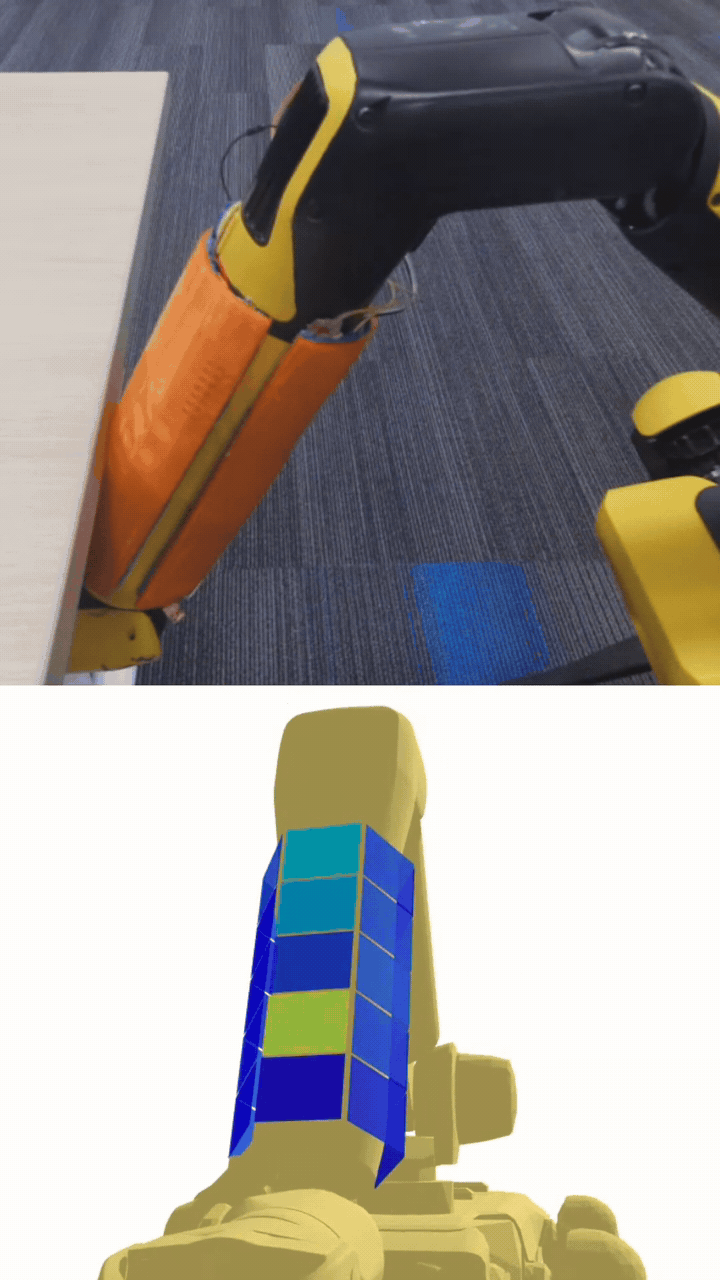
Quick previews of my research and collaborations. The sensing-skin loops keep the physical footage and sensor readouts together. Each preview links to its project and full recording.
Sensing skins and sensor readouts

Textile skin: contact avoidance
The robot responds to contact on its textile-covered arm. The lower panel shows the recorded taxel visualization from the same presentation video.

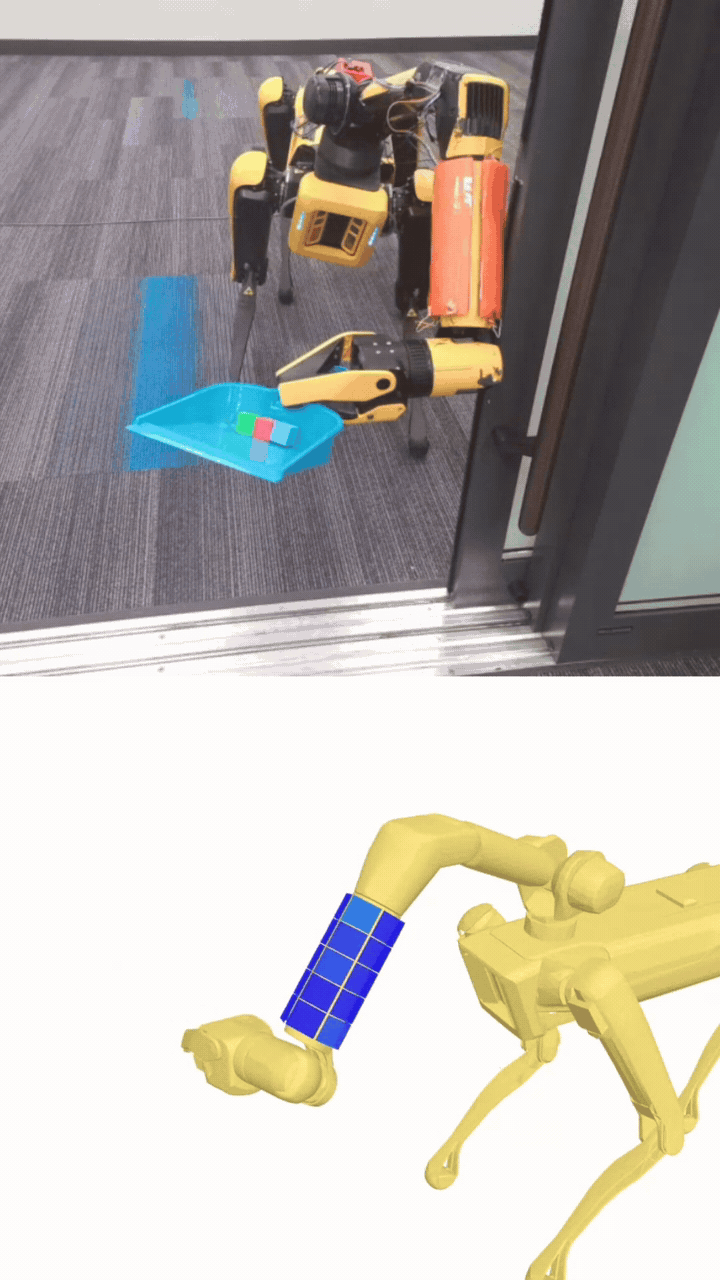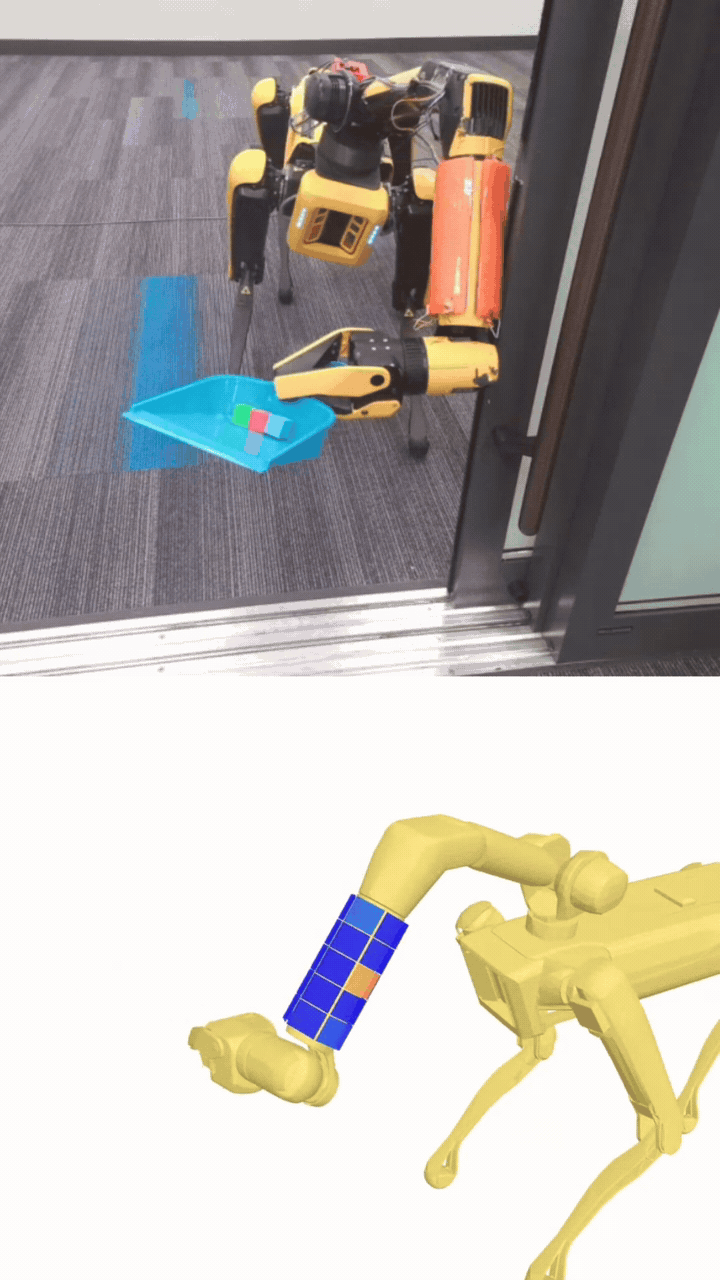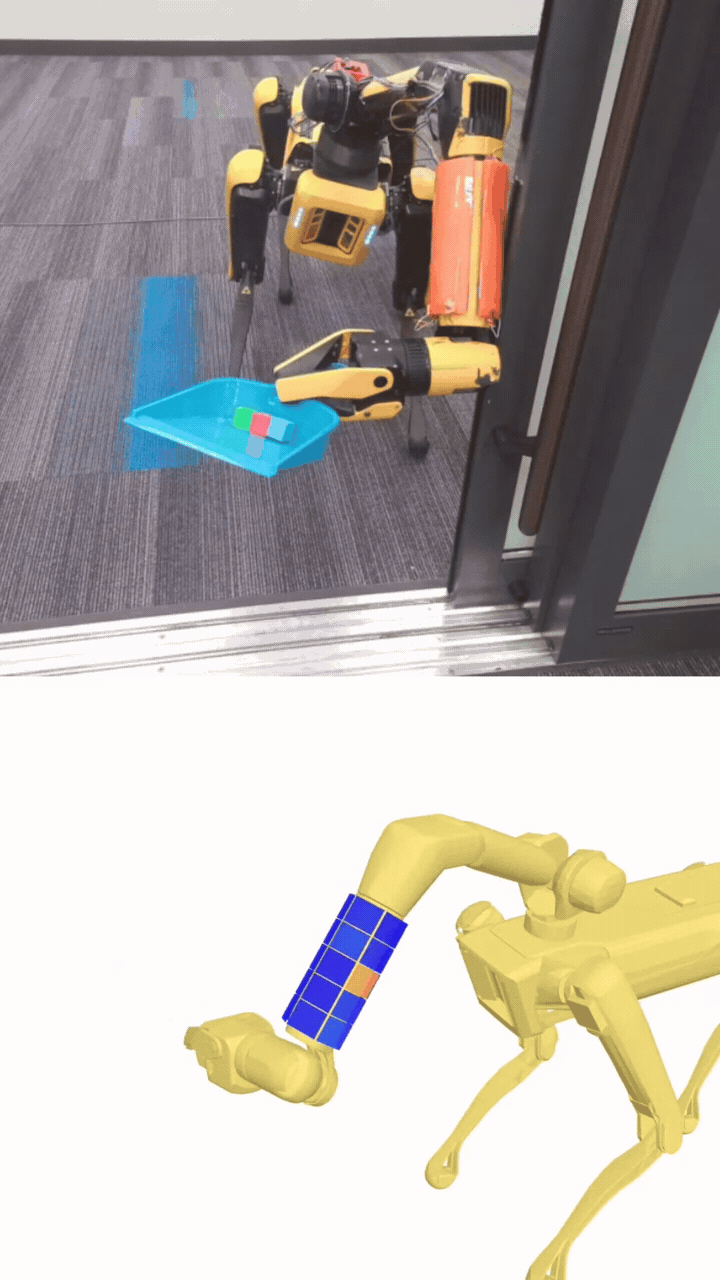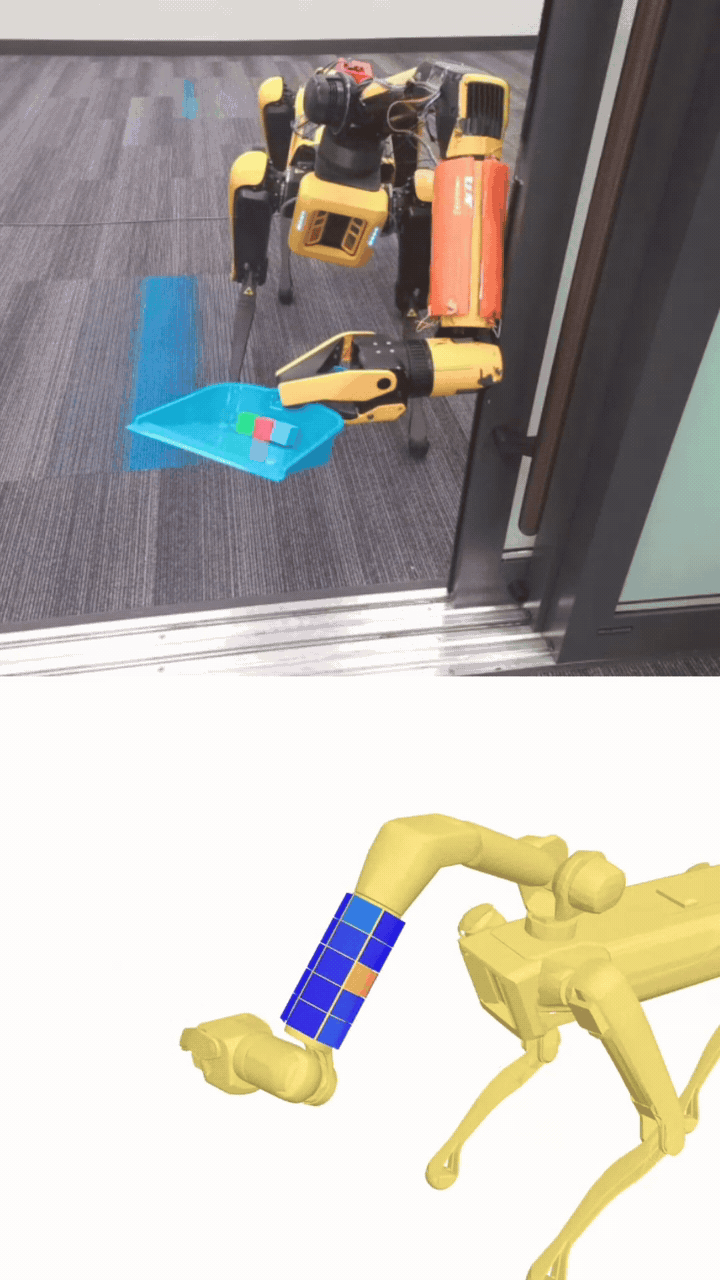
Printed skin: opening a door
Spot uses its printed arm skin during a door-opening task while holding a tray. Physical footage and the recorded sensor visualization appear together.

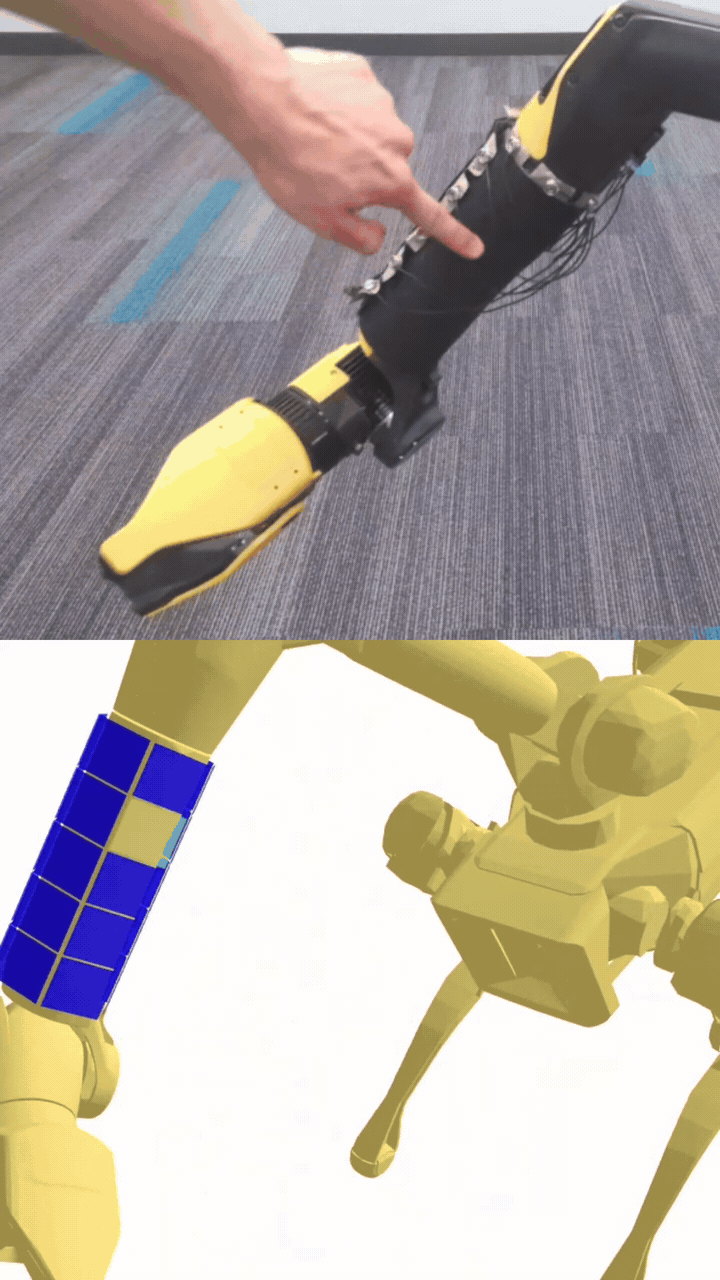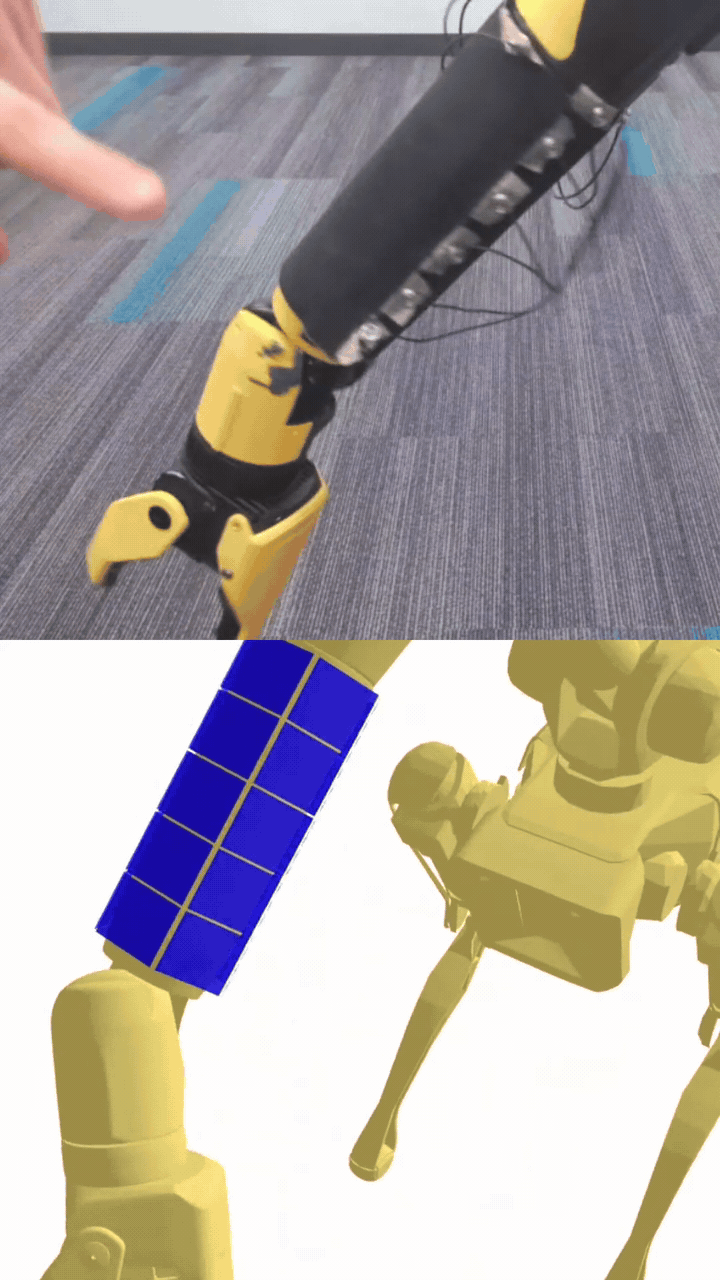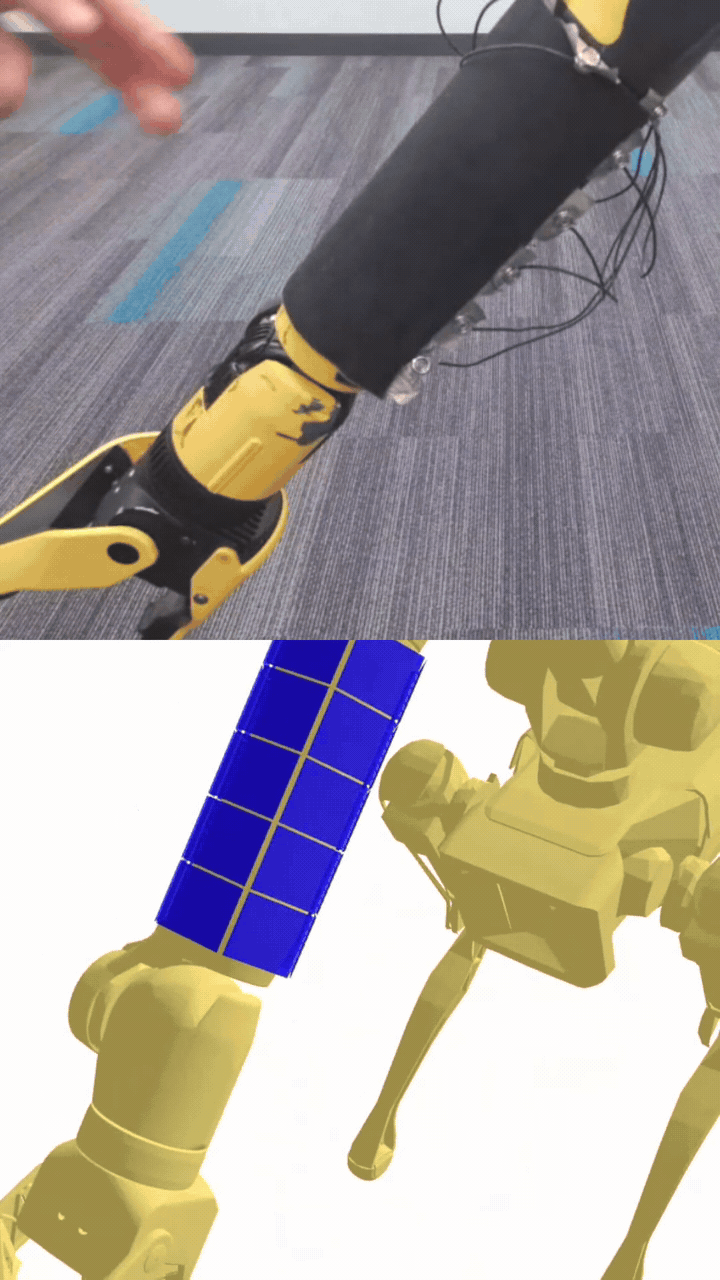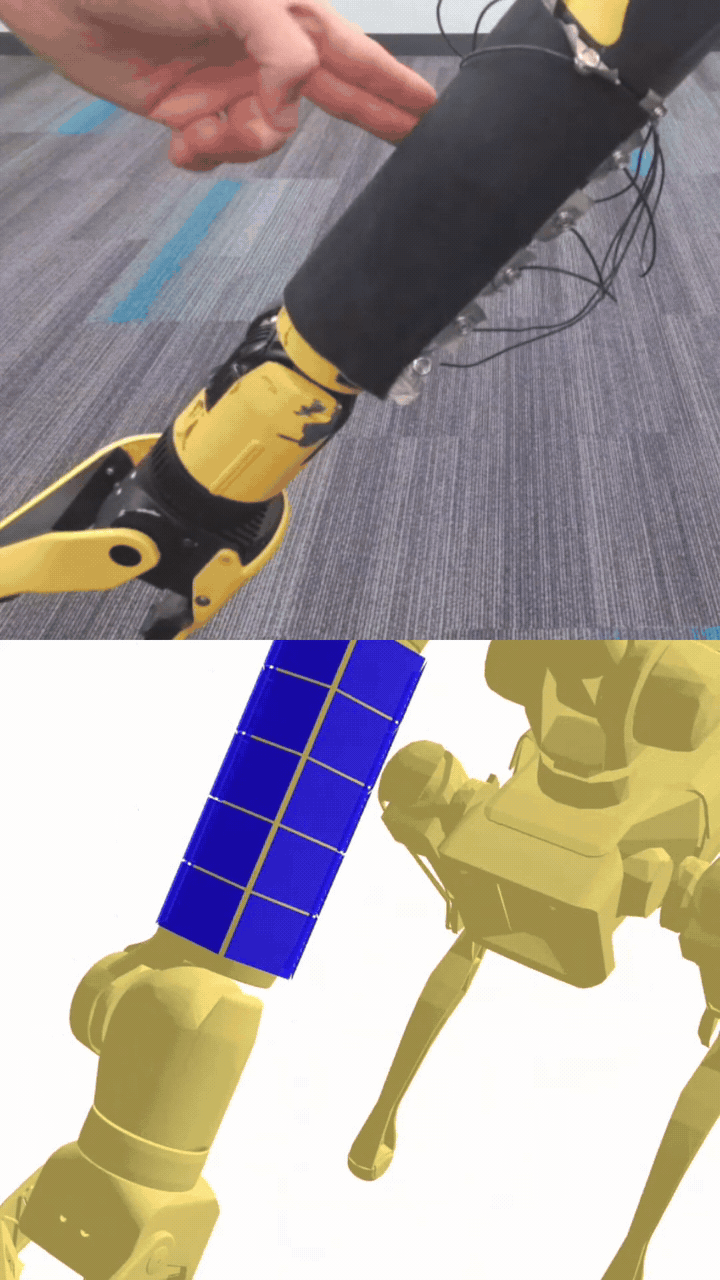
Textile skin: human interaction
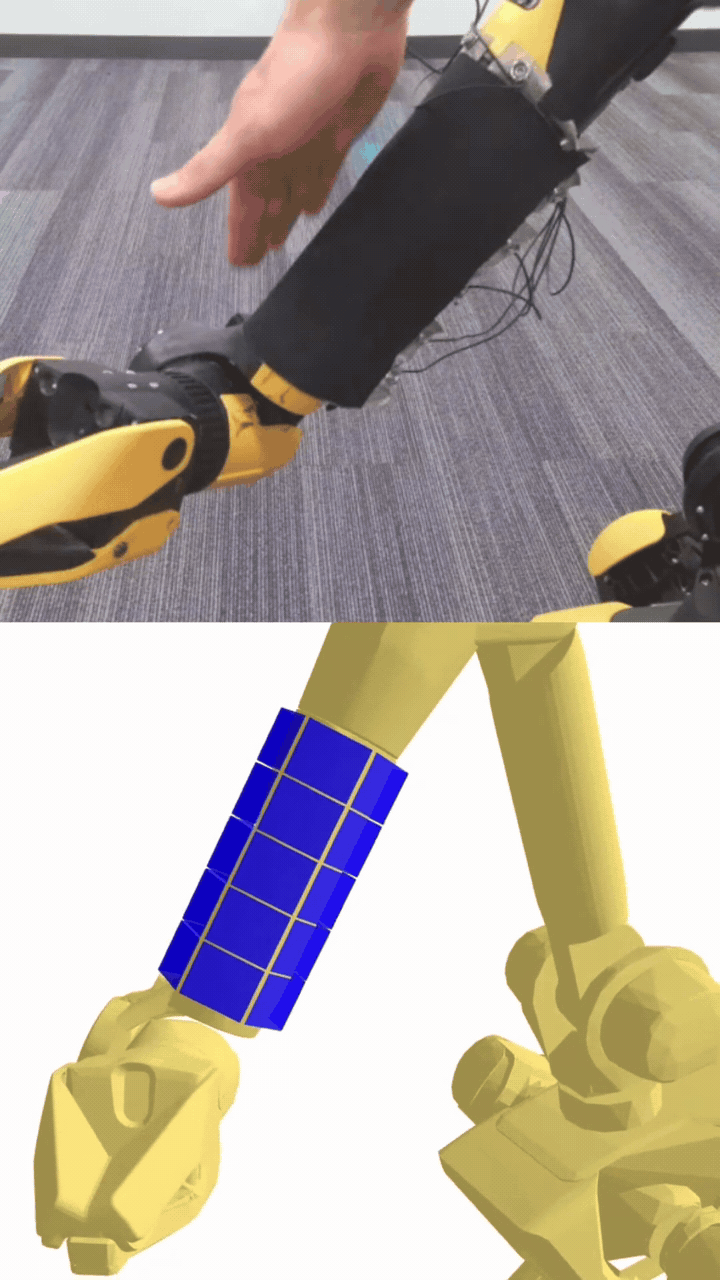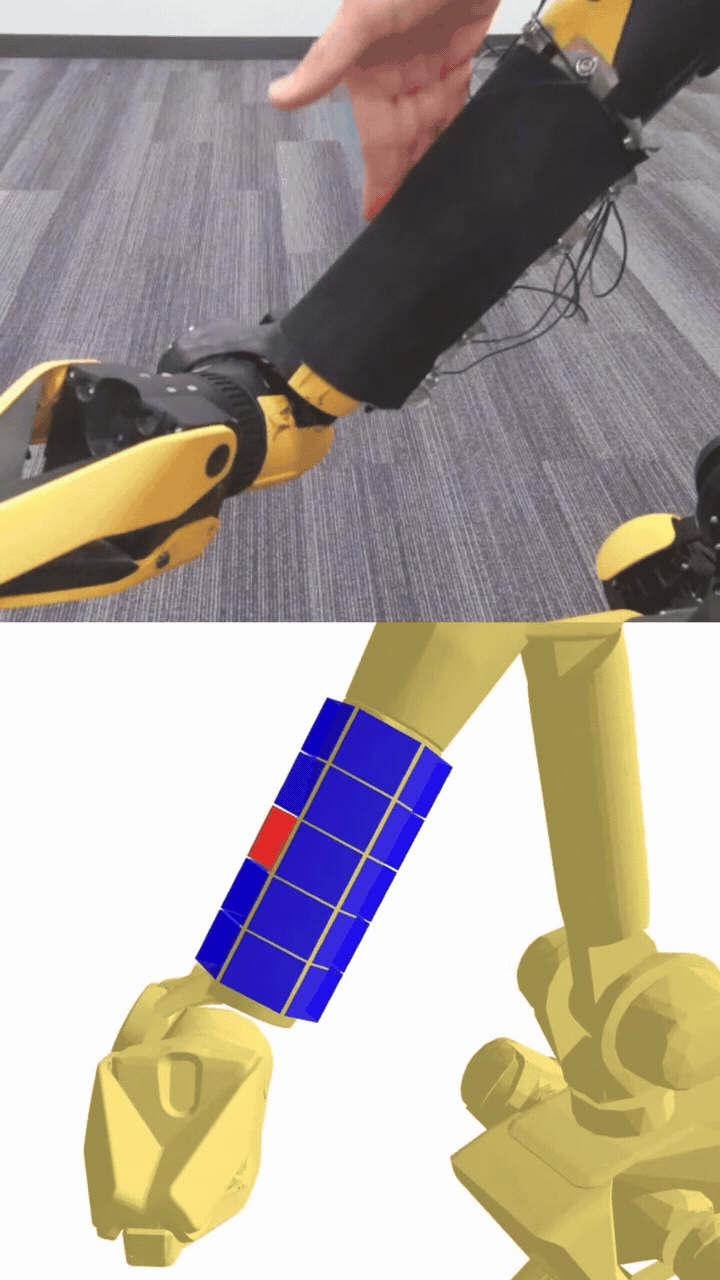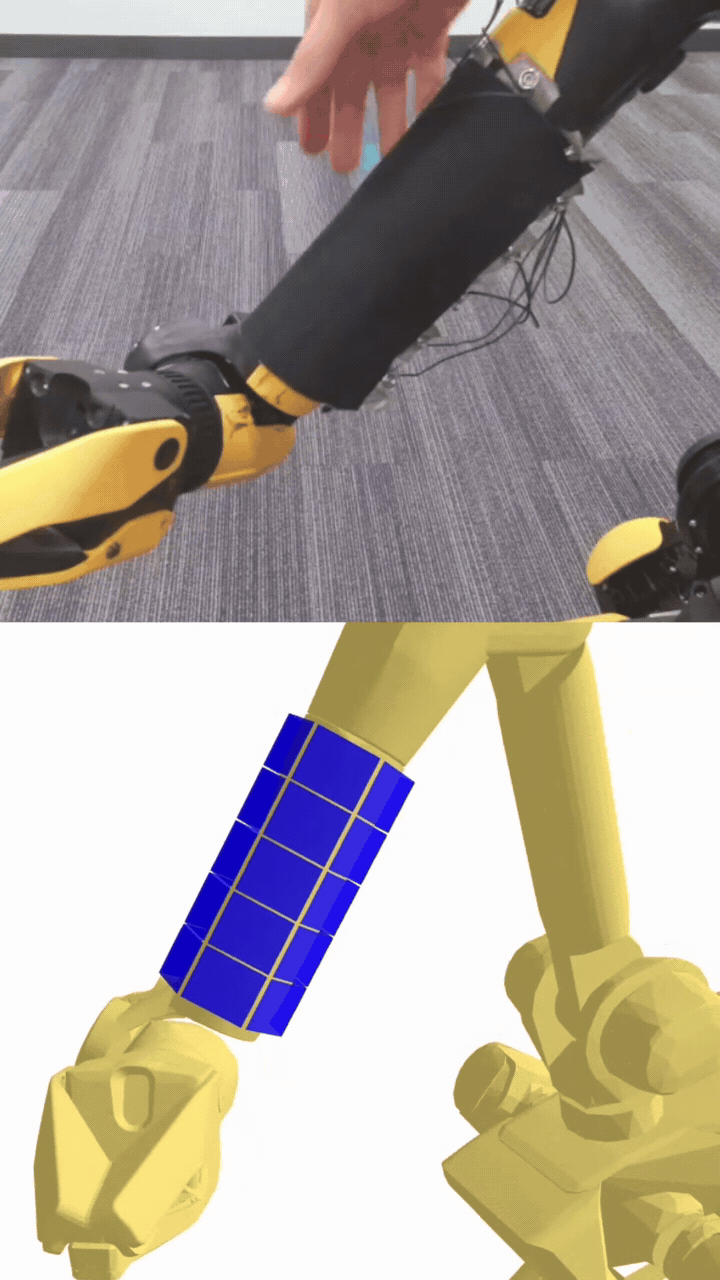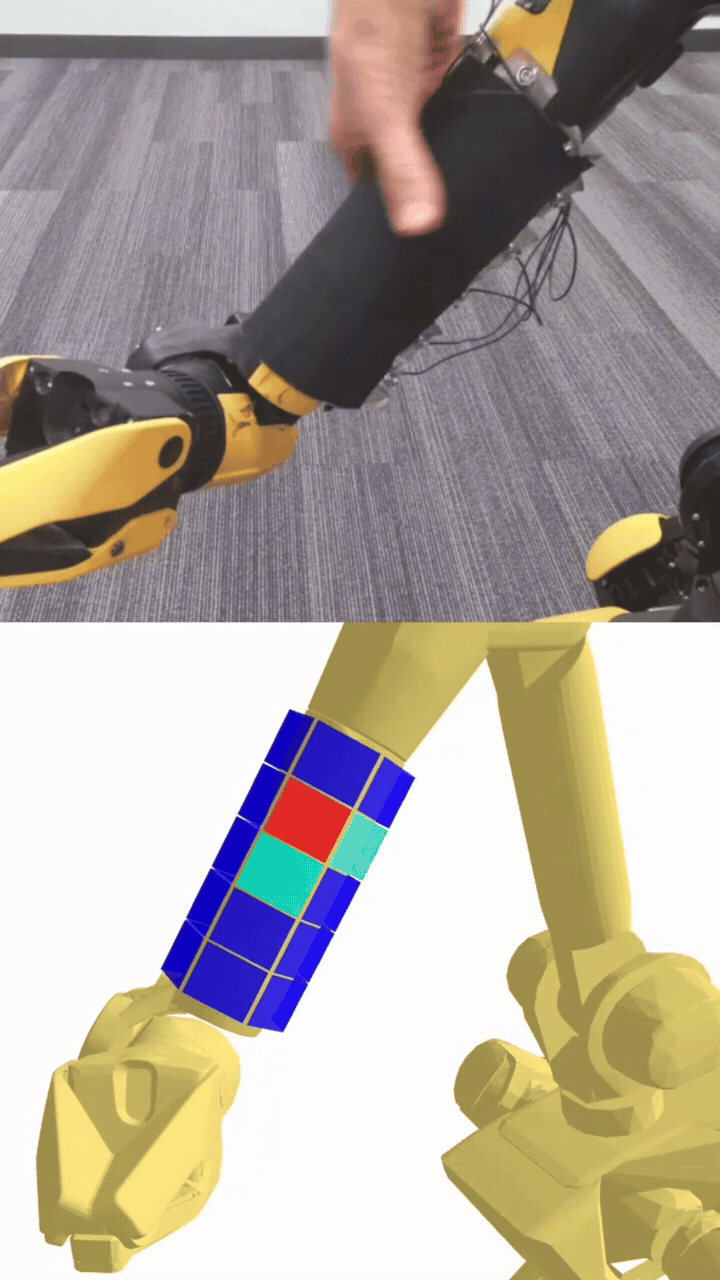
Hand contact with the textile skin is shown above the corresponding color-coded taxel view.

Printed skin during grasping
Spot grasps an object with the printed skin installed on its arm. The recorded taxel view remains visible throughout the clip.
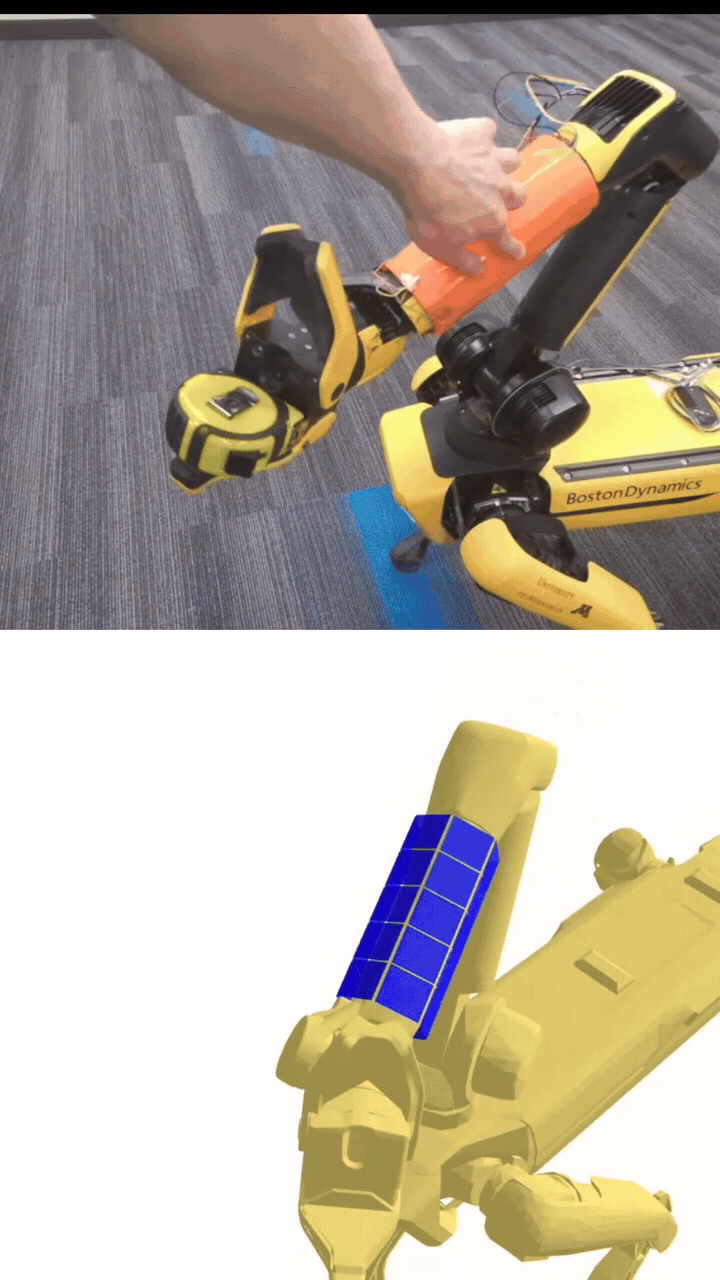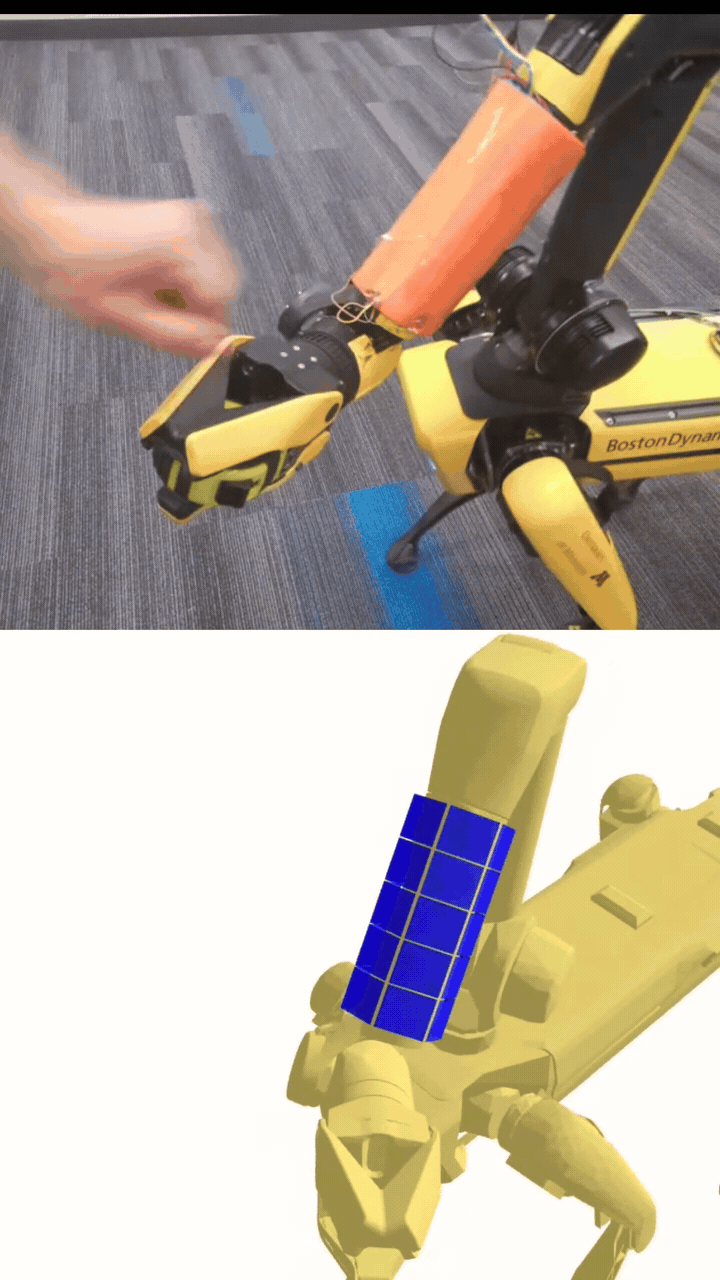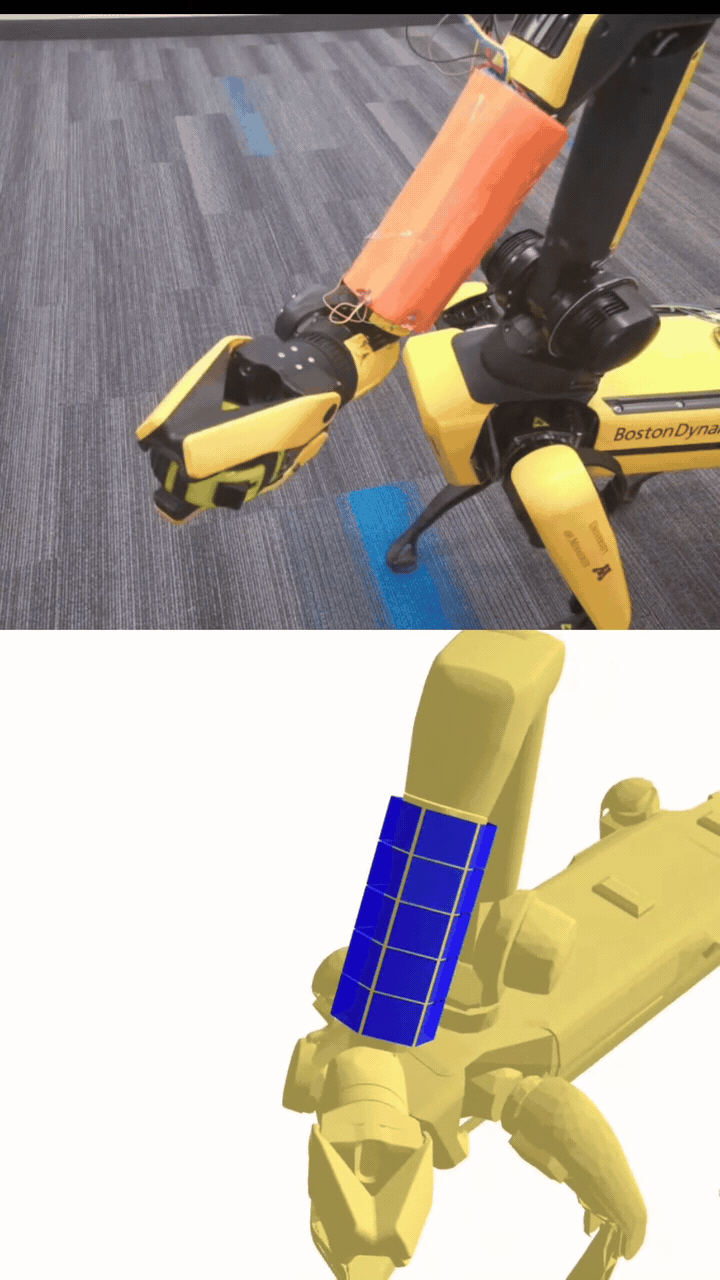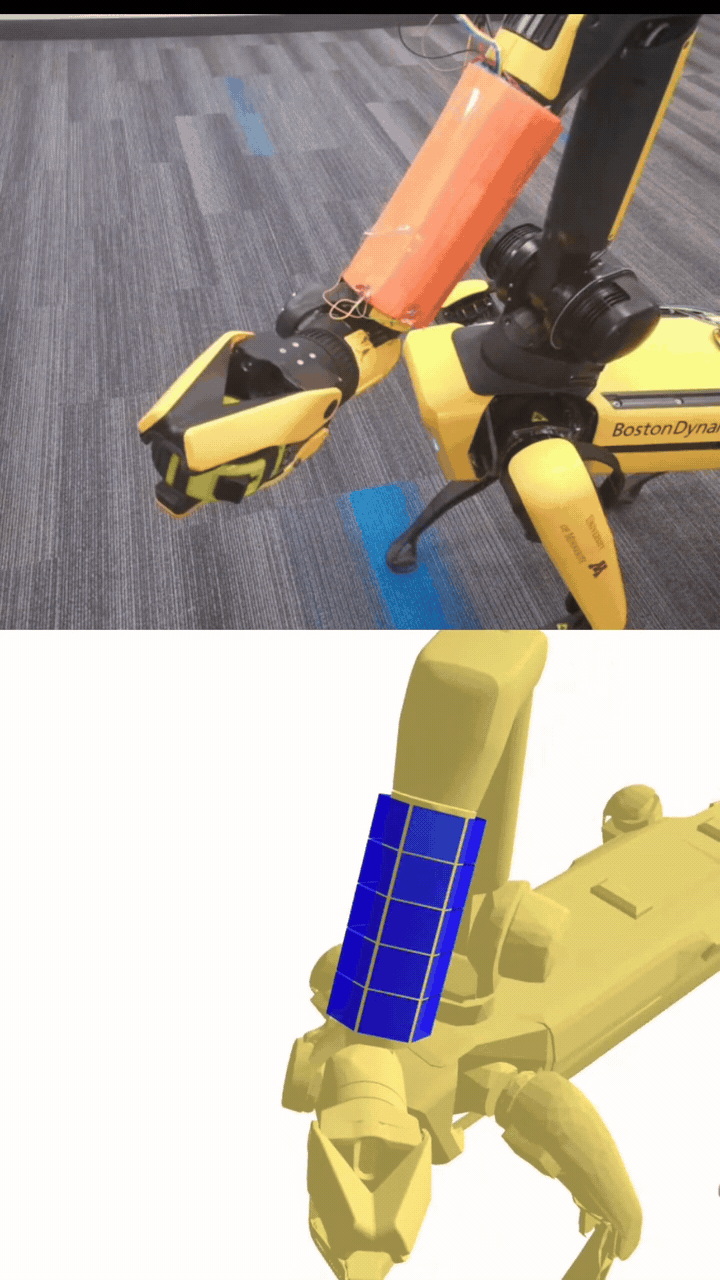

Textile skin: door contact
The textile-covered arm interacts with a door, shown together with its recorded taxel visualization.
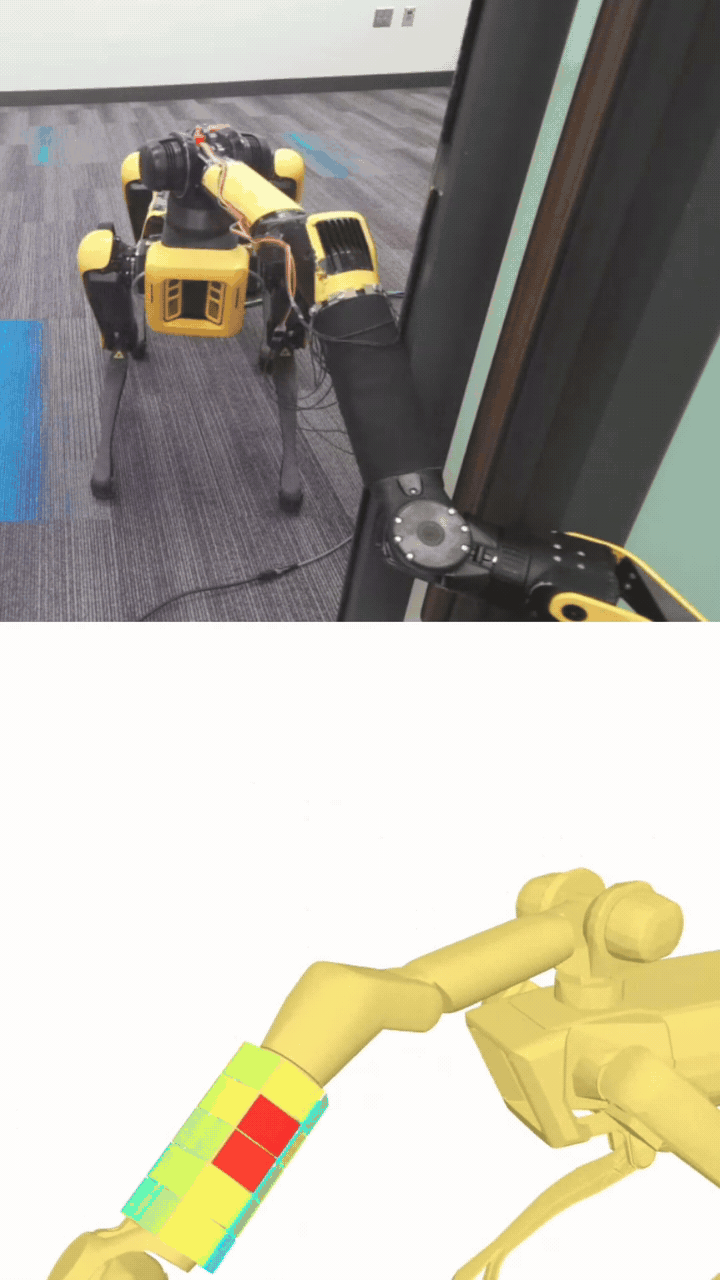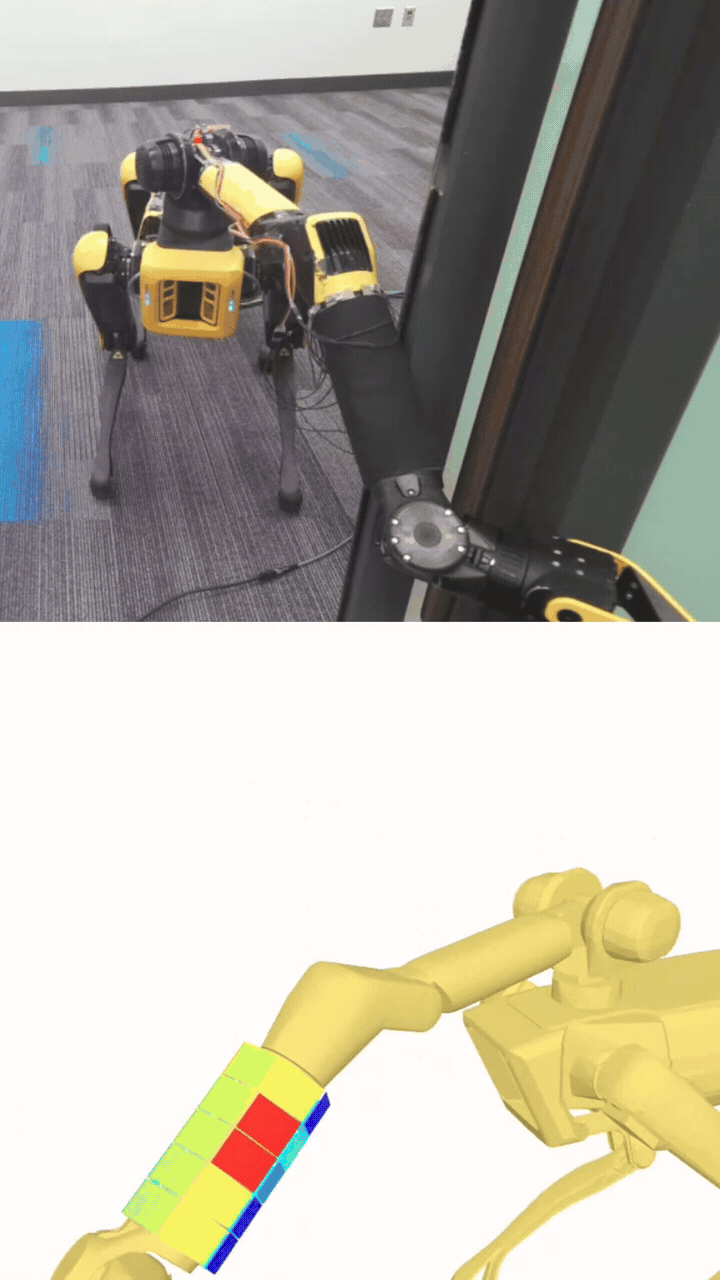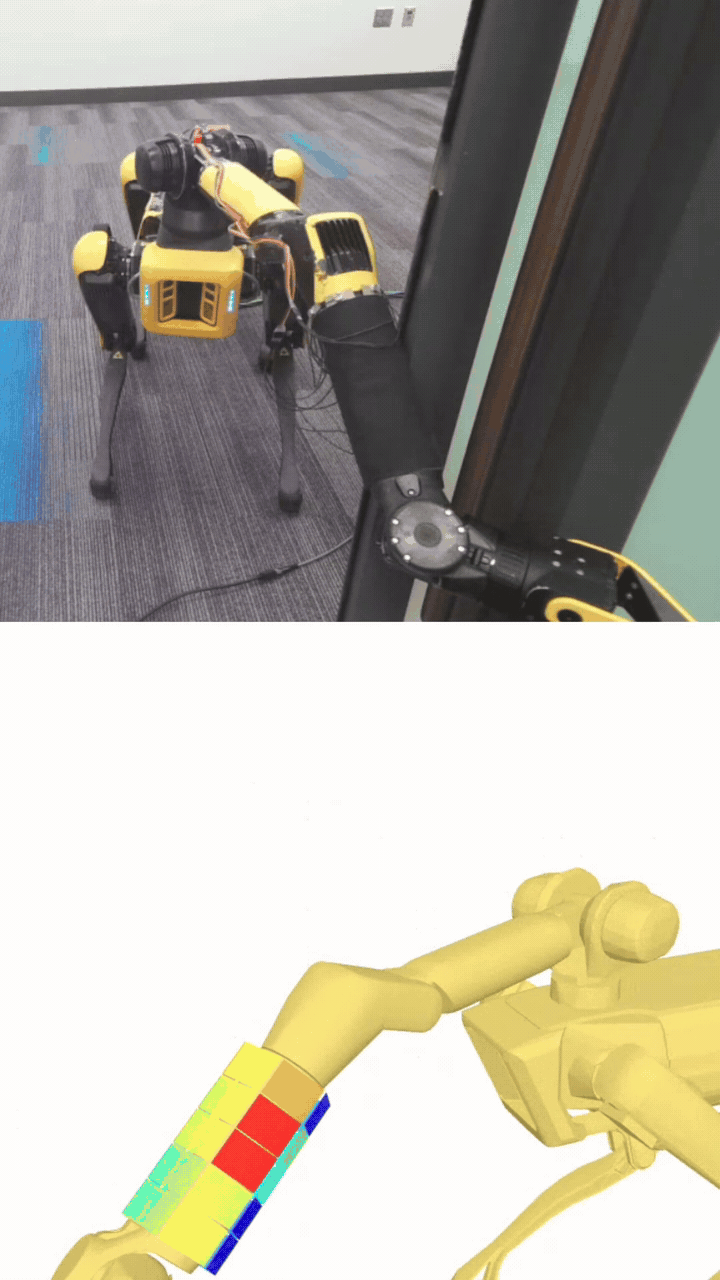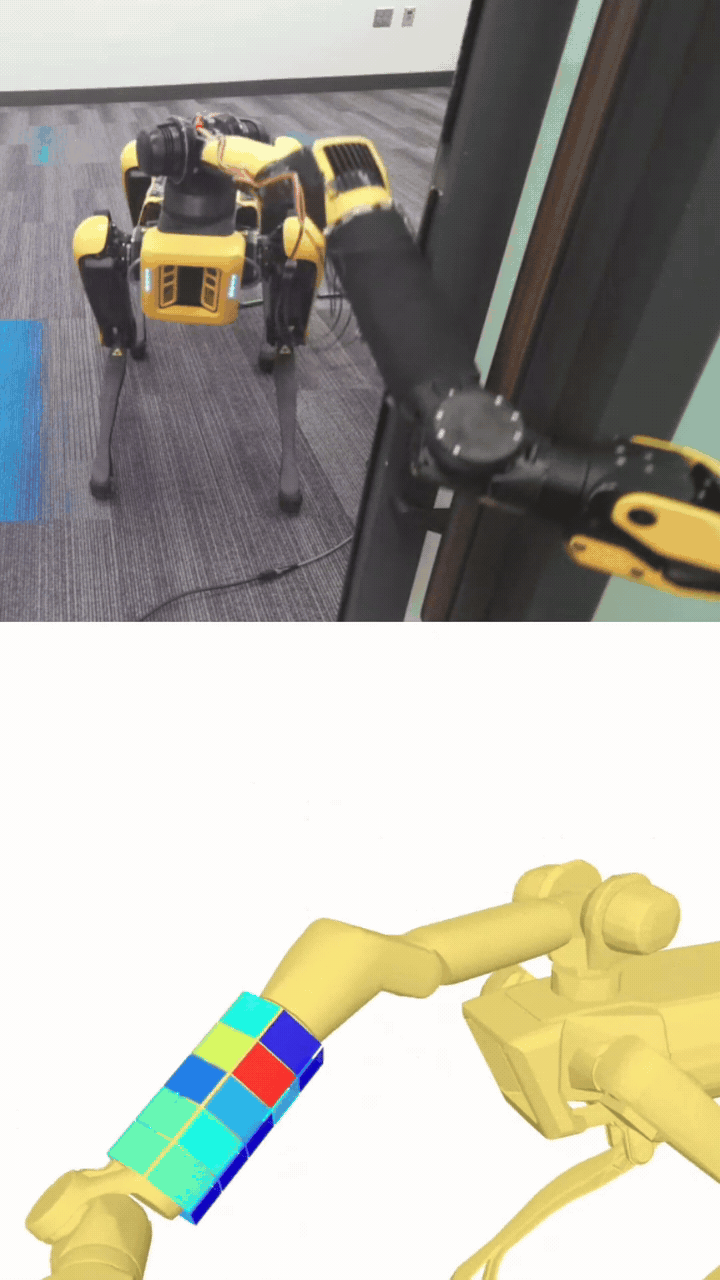

Printed skin: table contact
The printed skin contacts a table. The lower panel makes the recorded taxel response visible alongside the physical interaction.
Robots in action

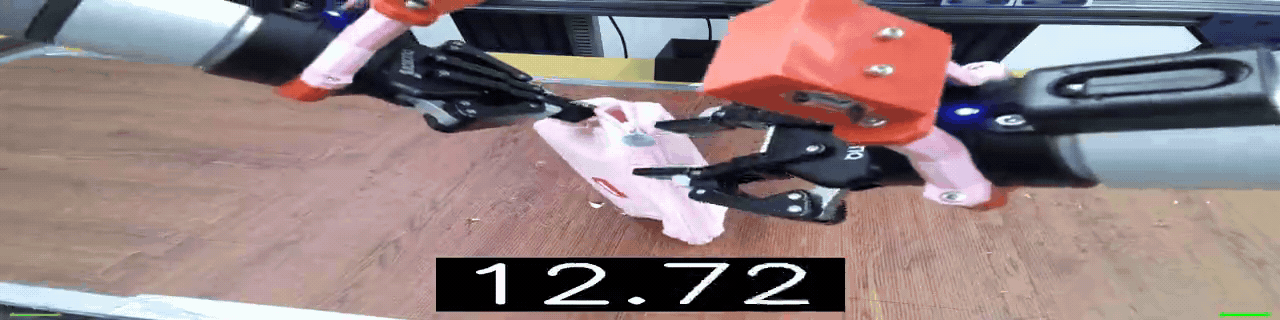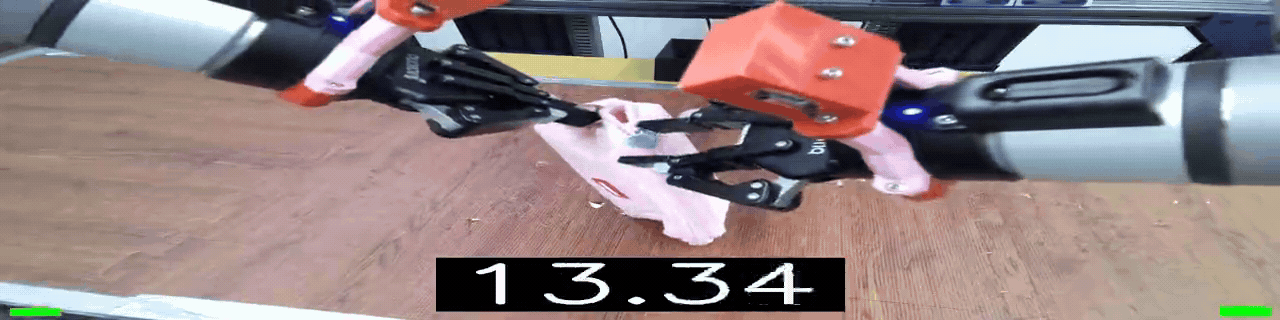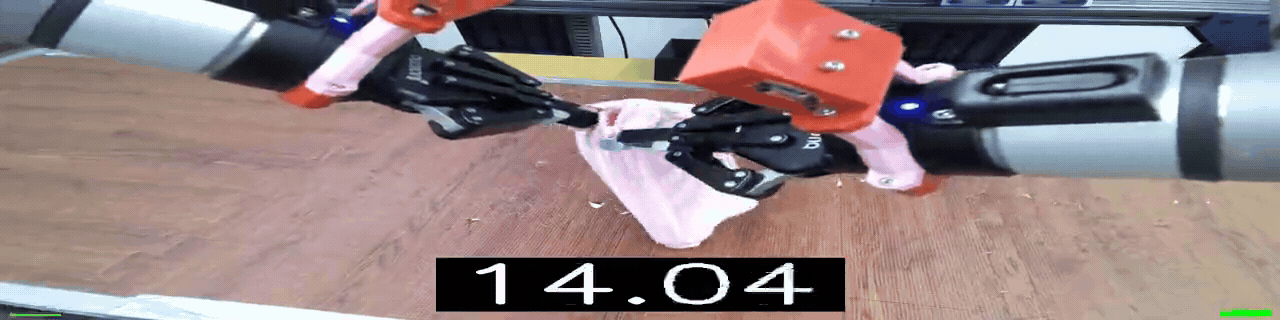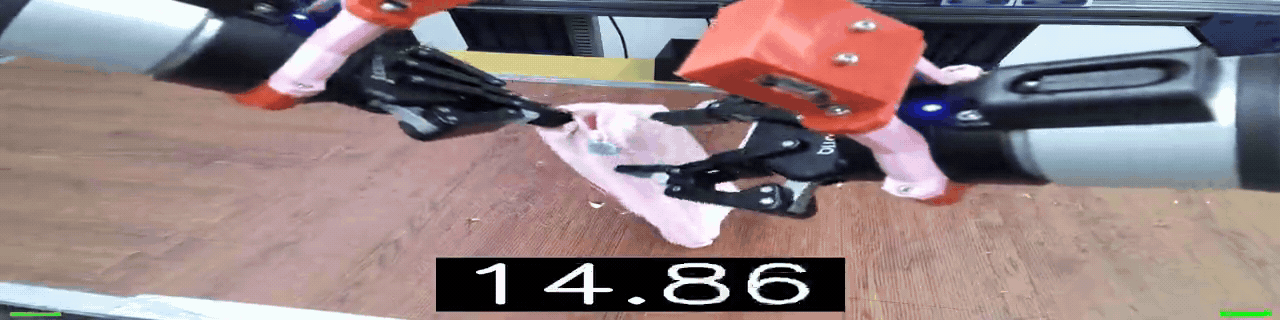
SPARK-Remote bimanual manipulation
An operator performs a bimanual bag task using the SPARK-Remote system. This recording shows human teleoperation.

AugInsert assembly study
Real-world augmentation study video from our AugInsert project. The paper also evaluates visual-force policies in simulation.

Talk Through It
Our project introduction to robot manipulation learning through interactive feedback from an end user.

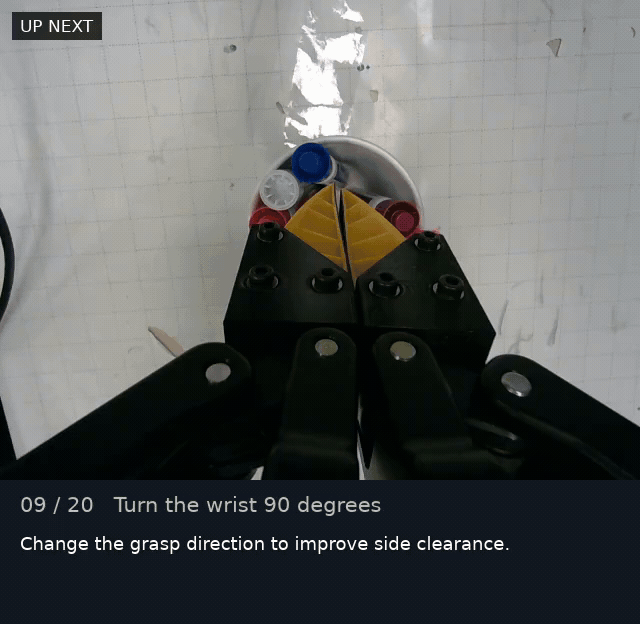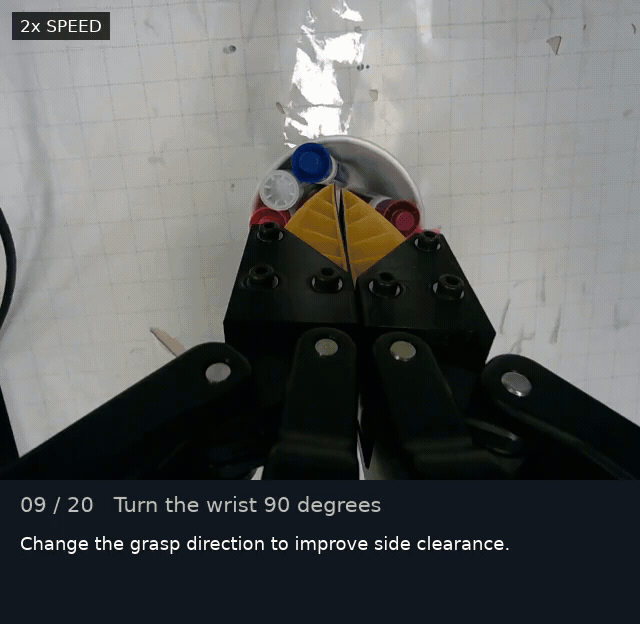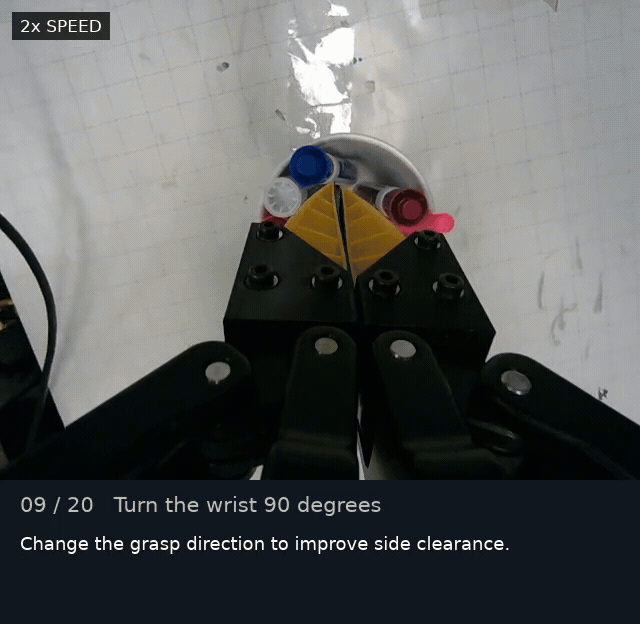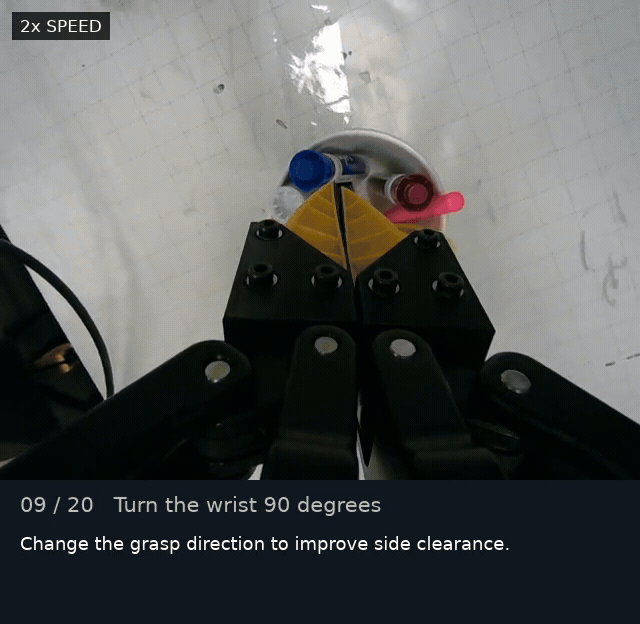
Astra / GPT-6 on the Thunder UR5e
An accelerated recording of one blue-marker pickup using wrist-camera observations. The original run took about 15 minutes; this is not a reliability benchmark.

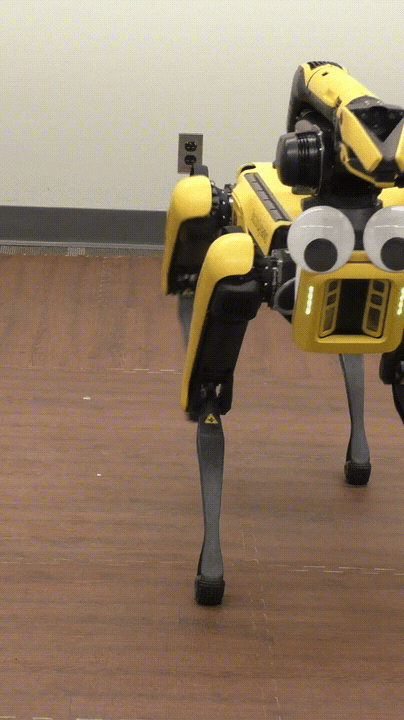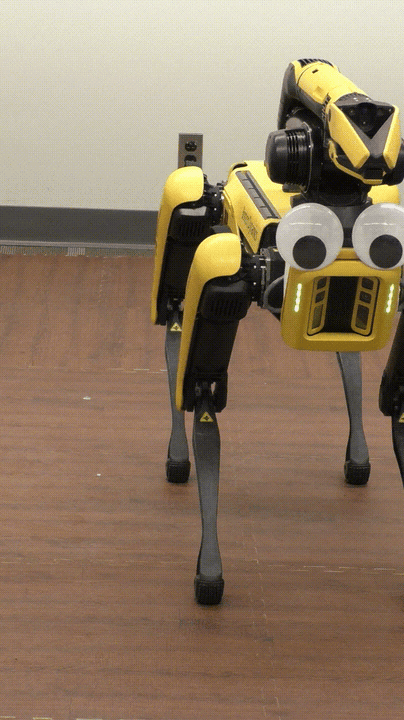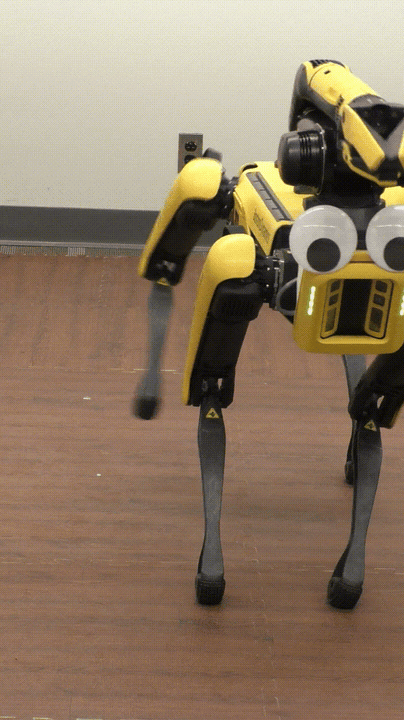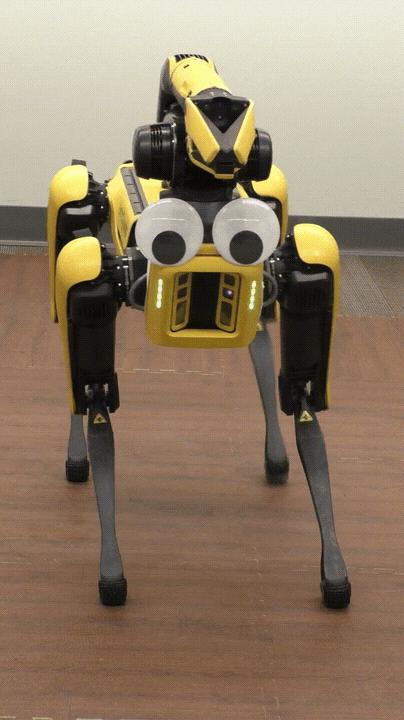
SpotNLP: rotation gesture
A short loop from the project's existing rotation-gesture GIF. The full project includes language interaction and navigation recordings.
Simulation studies

G1 walking policy
Walking rollout from the frozen simulation evaluation, seed 2042. Physical robot transfer has not been established.
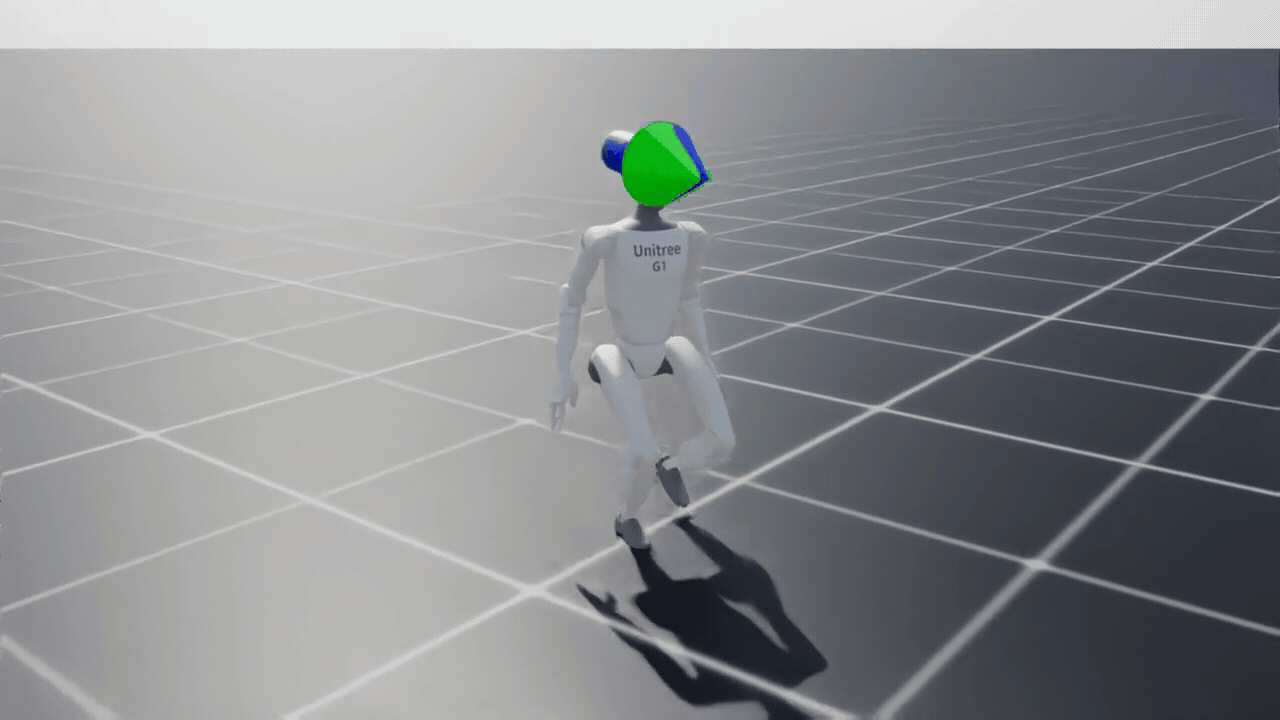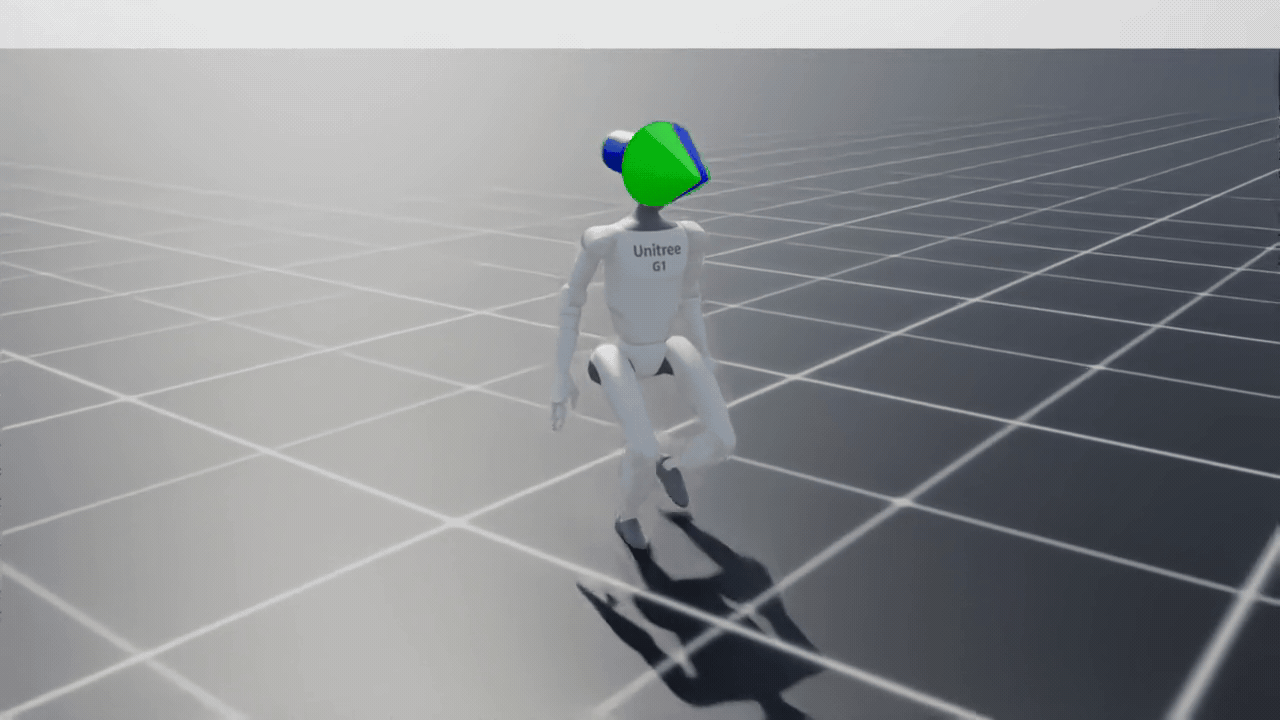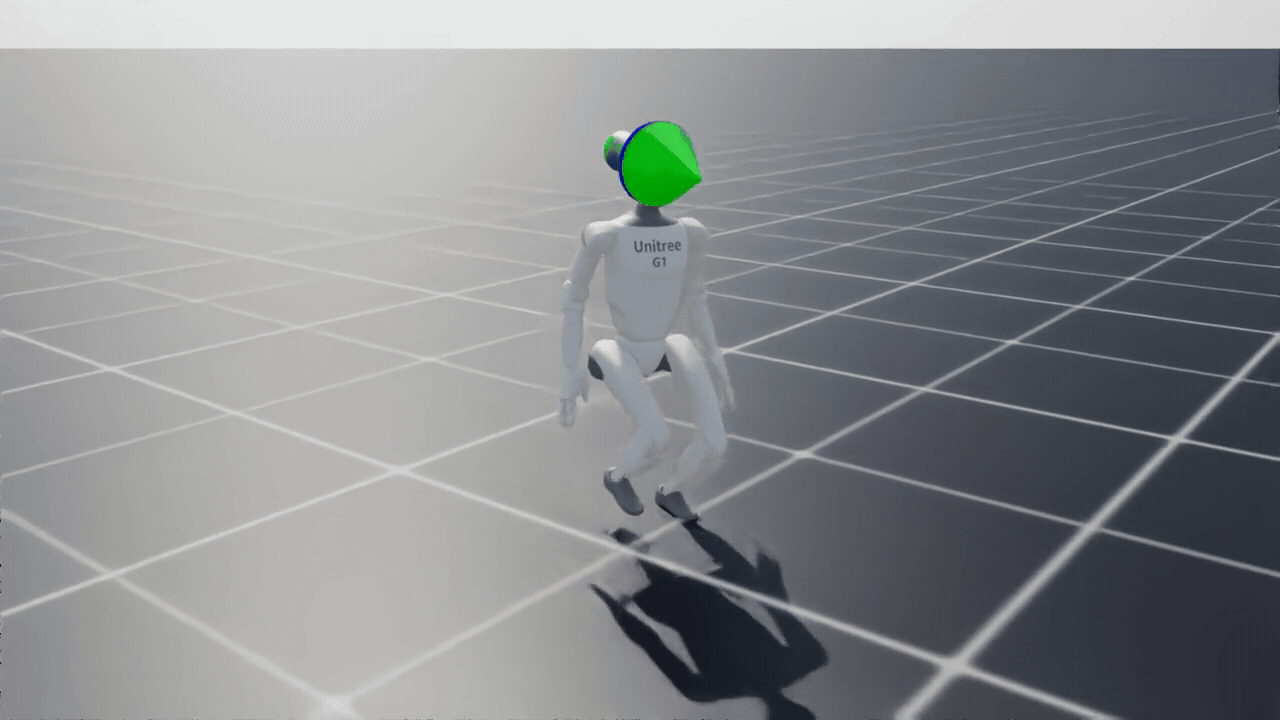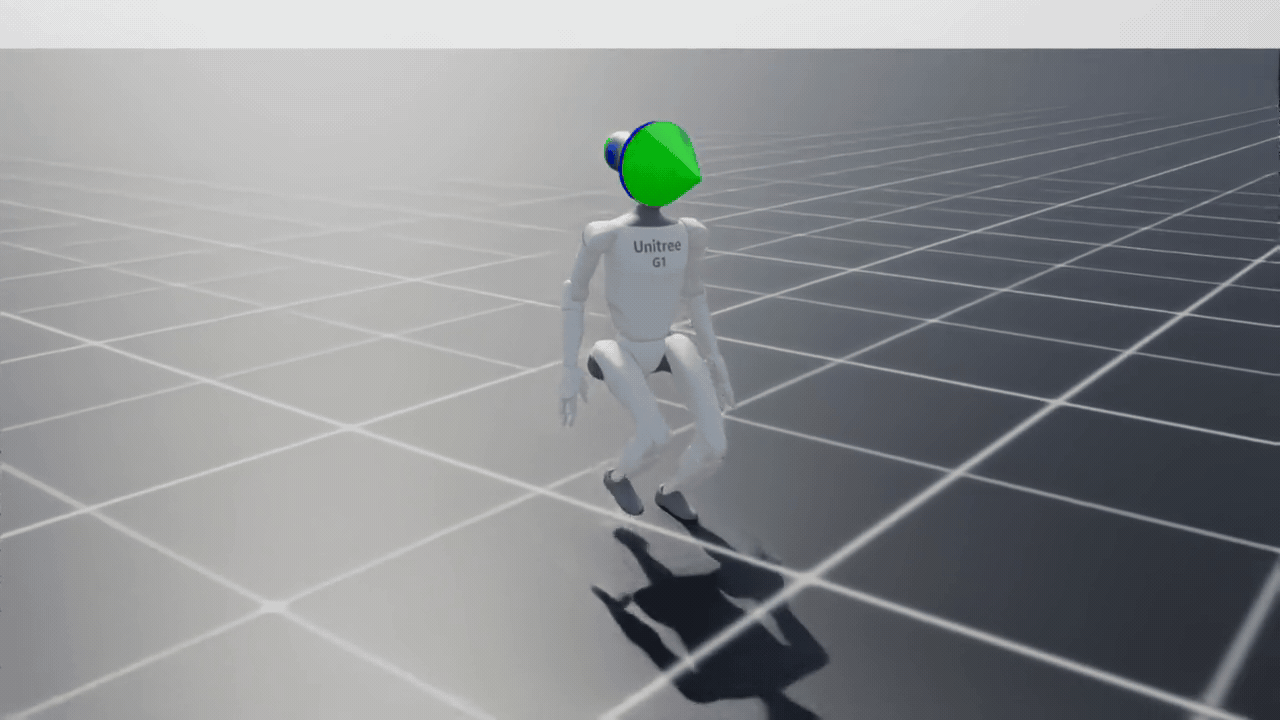

G1 supported pickup
Supported-reach pickup development trace, seed 5146. Assistance is present; unassisted pickup remains unvalidated.
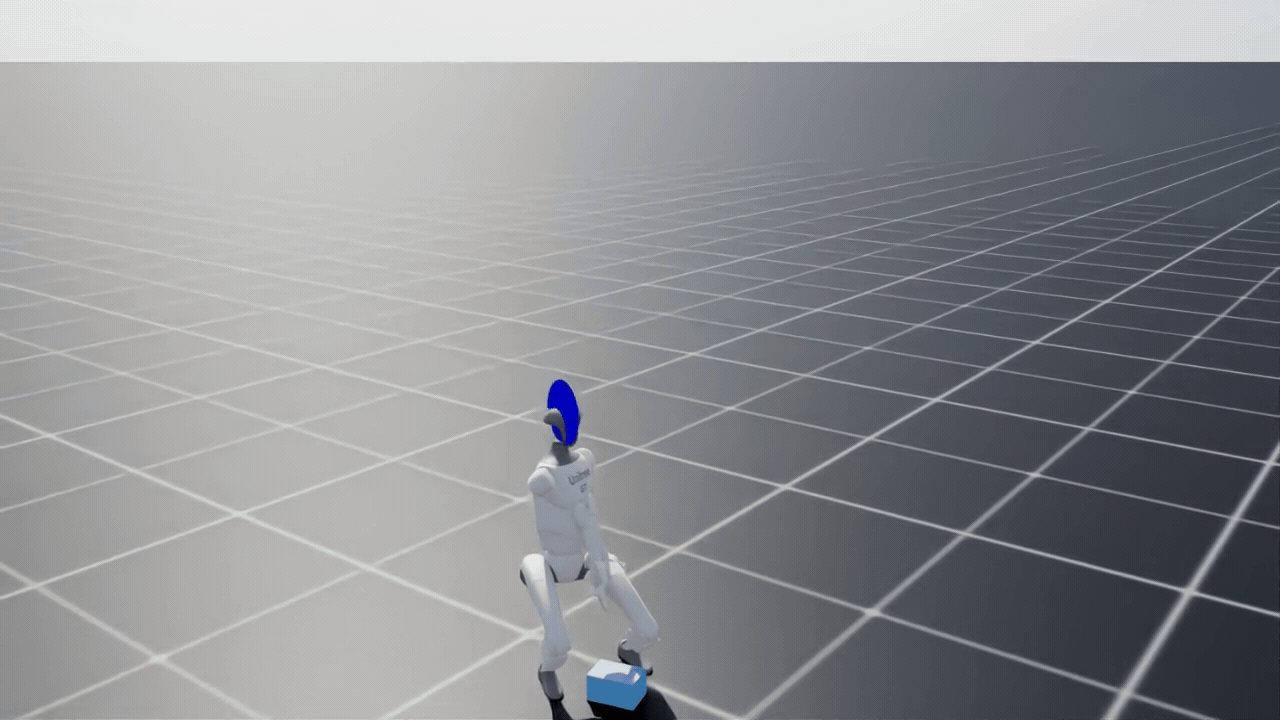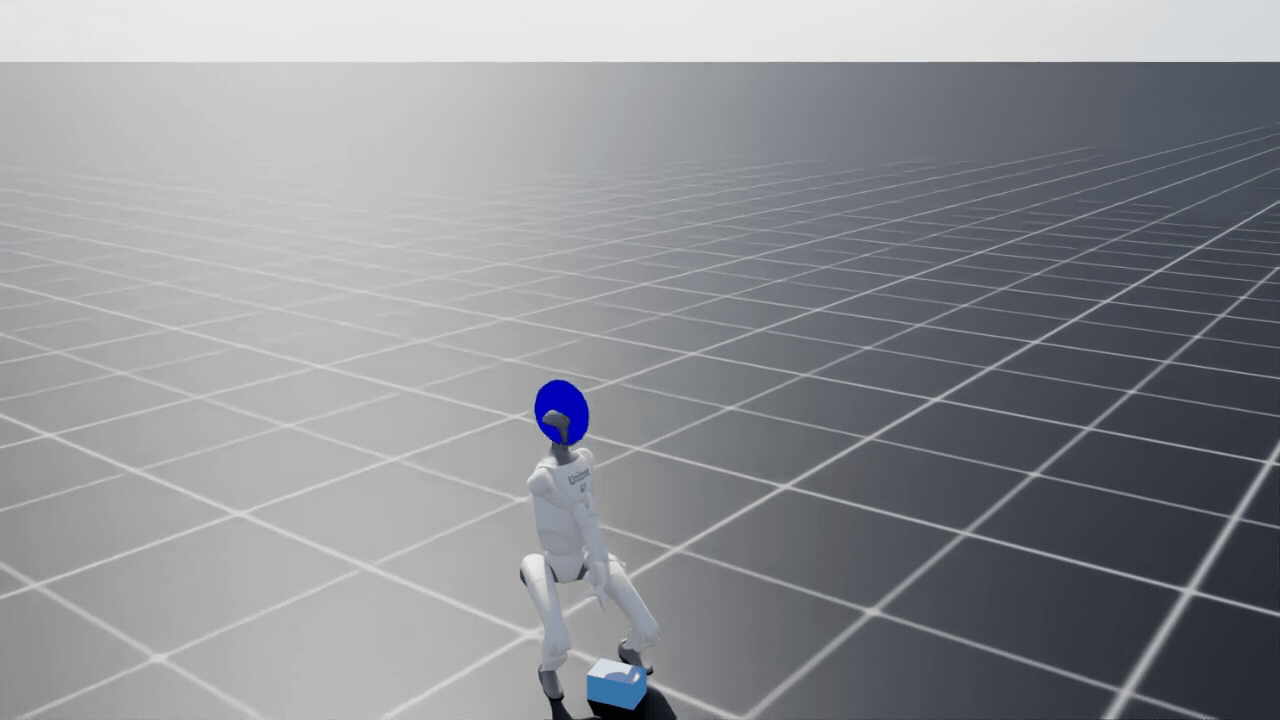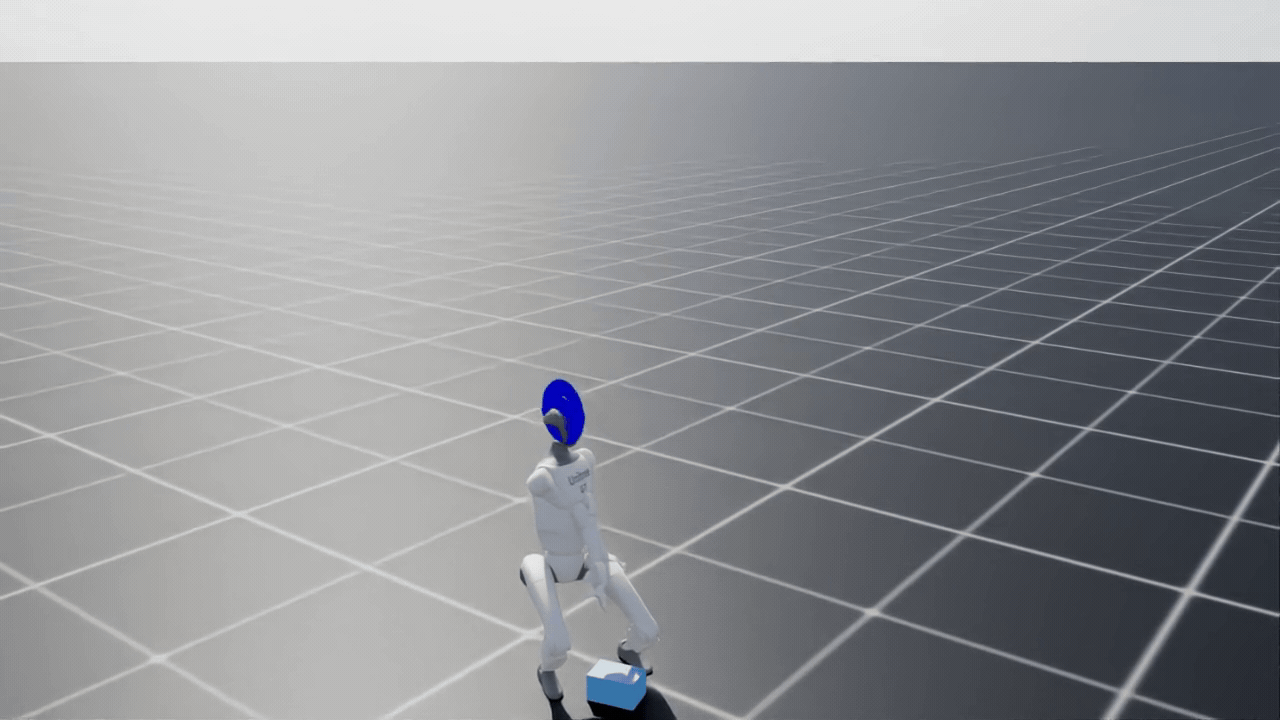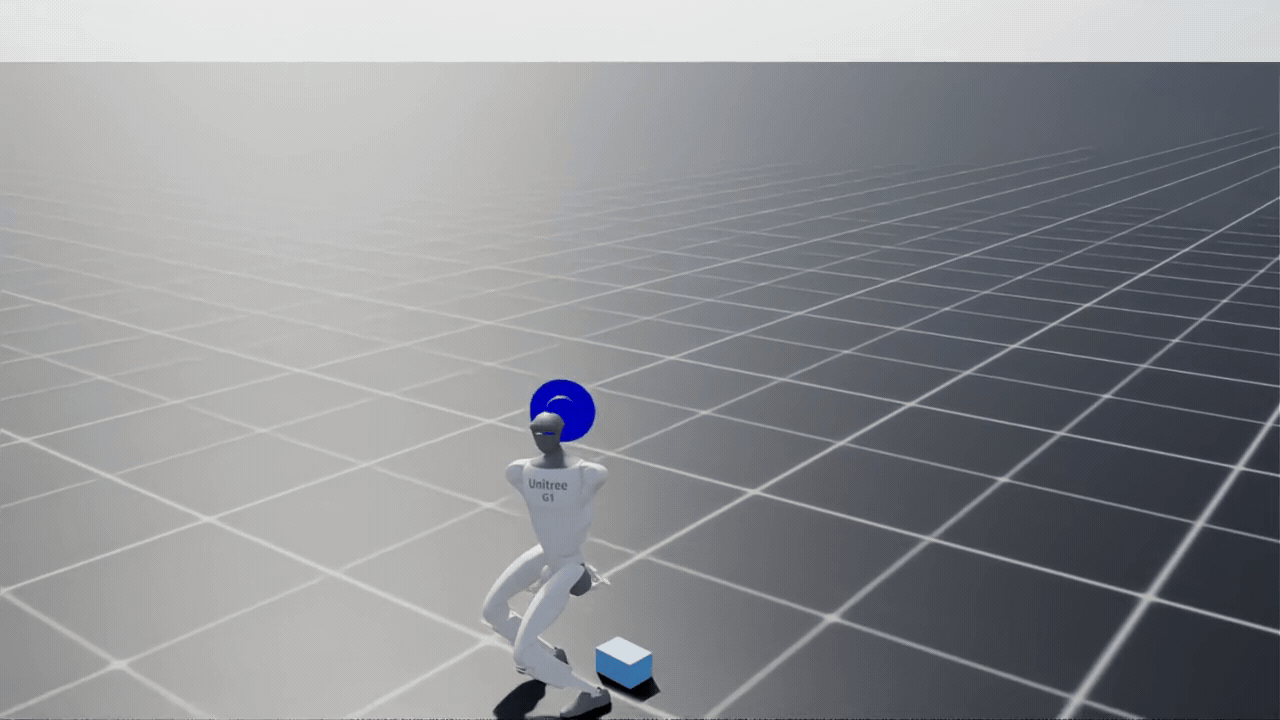

G1 large-object enclosure
Near-miss enclosure replay, seed 9479. Sustained strict-enclosure success remains open.
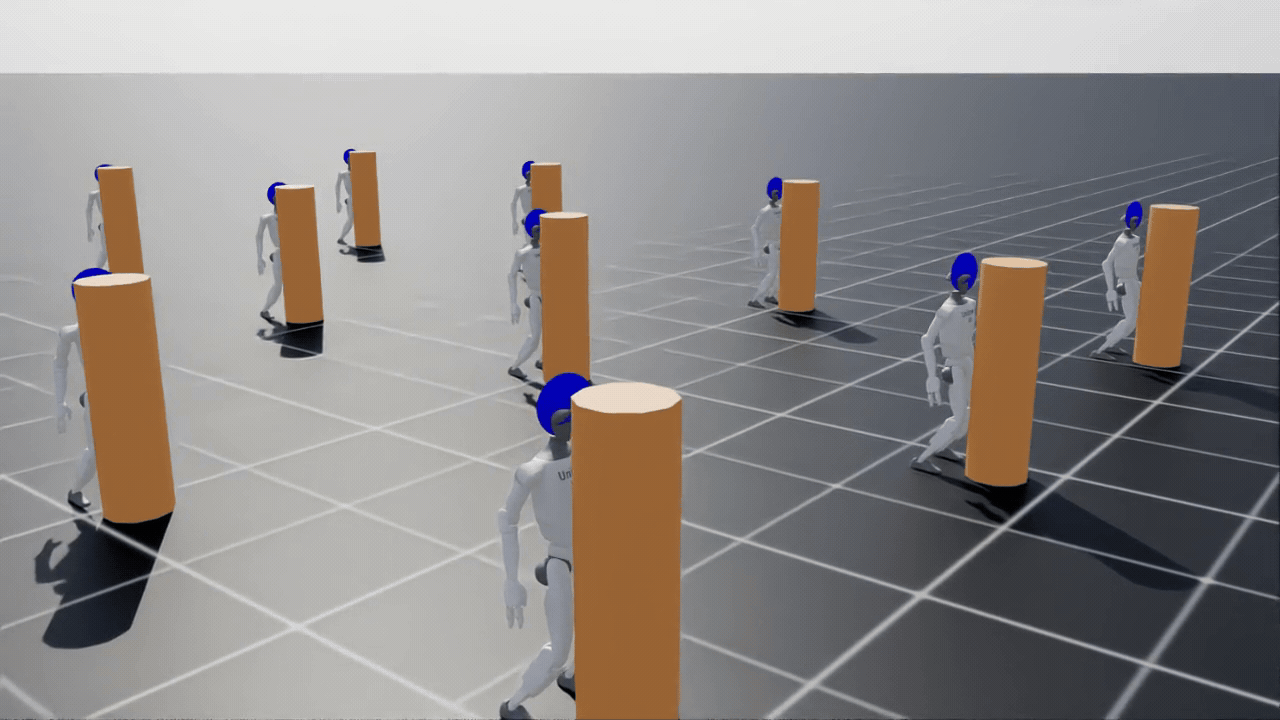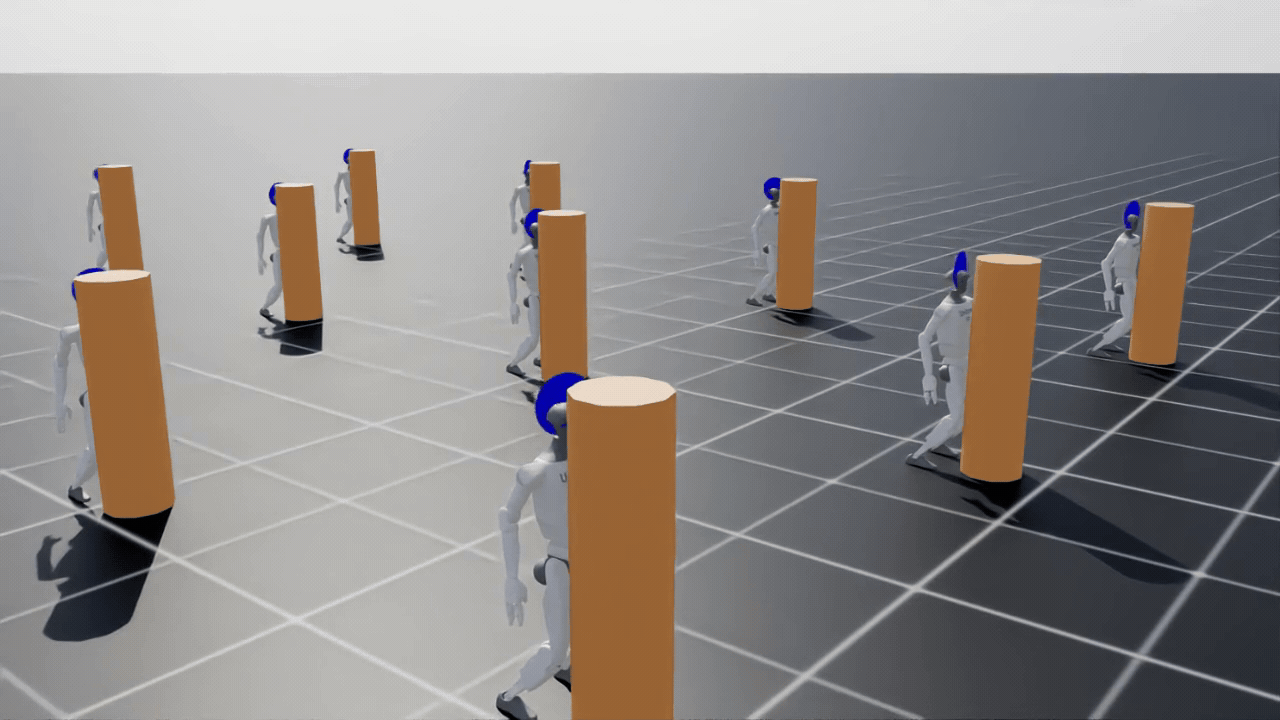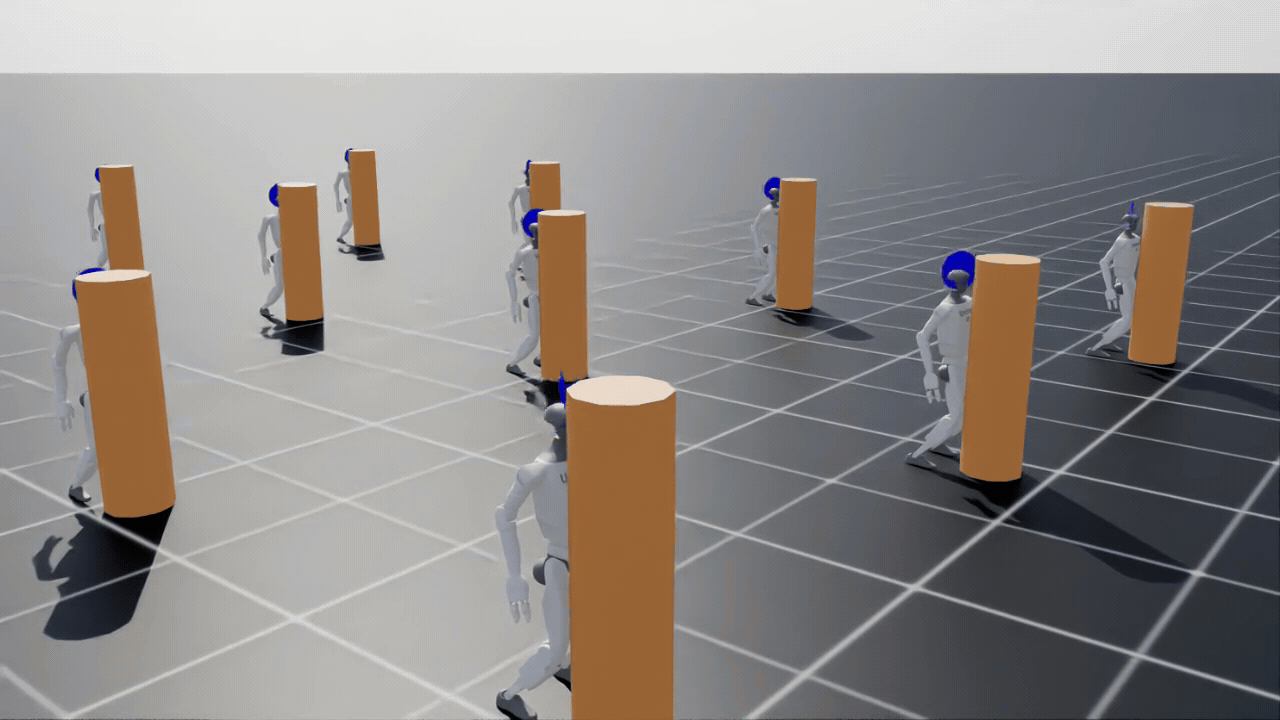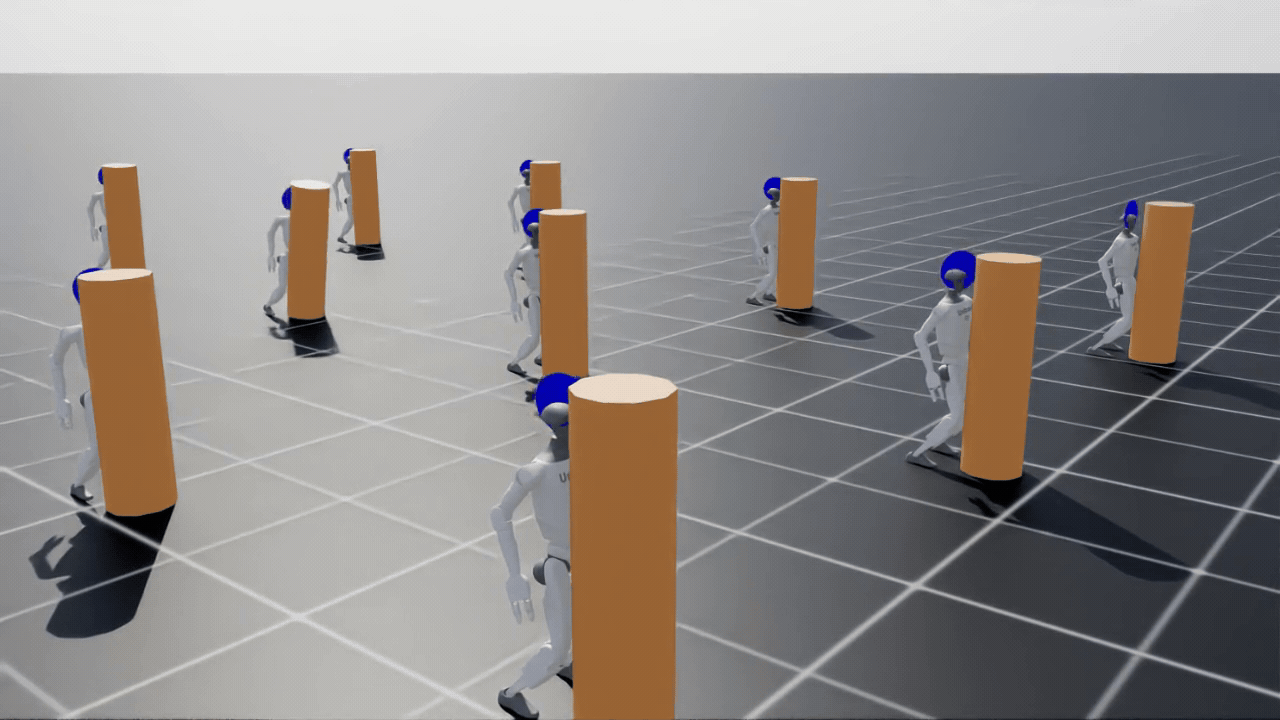

Alem coalition behavior
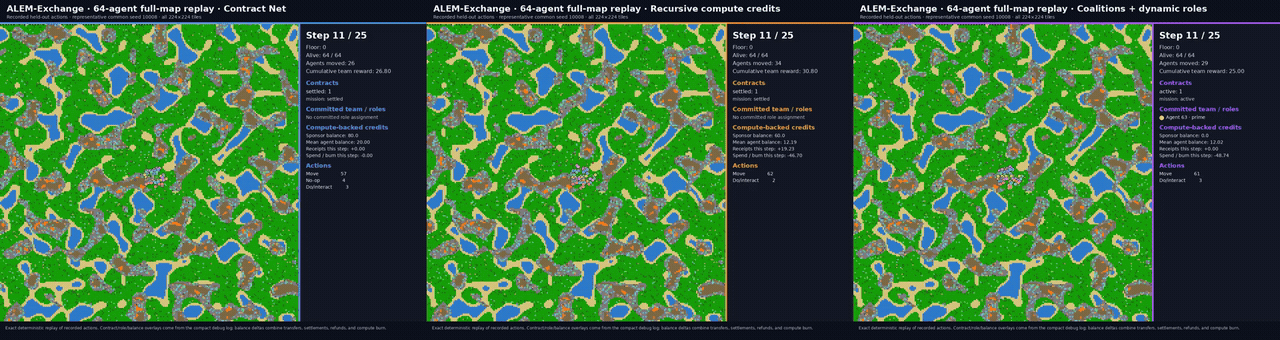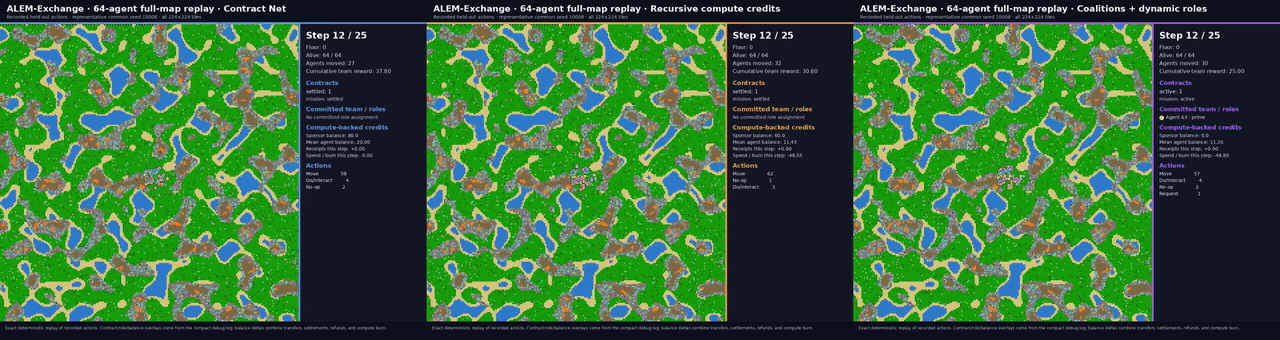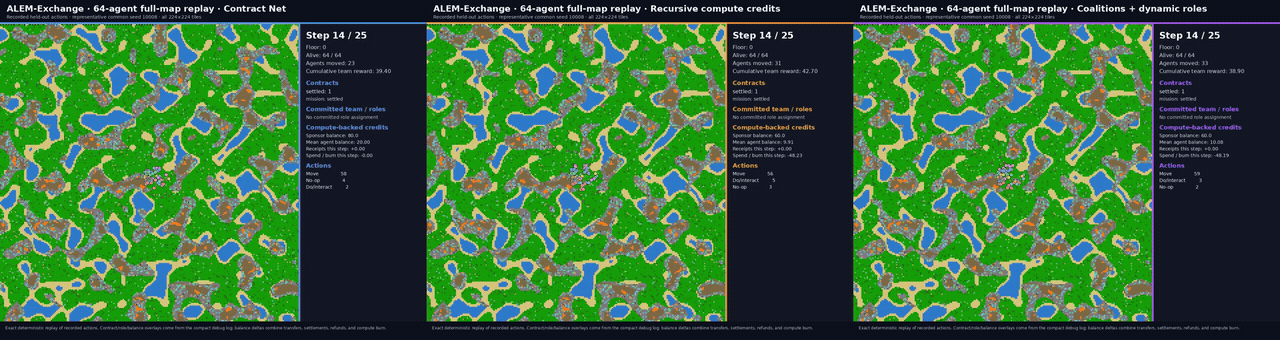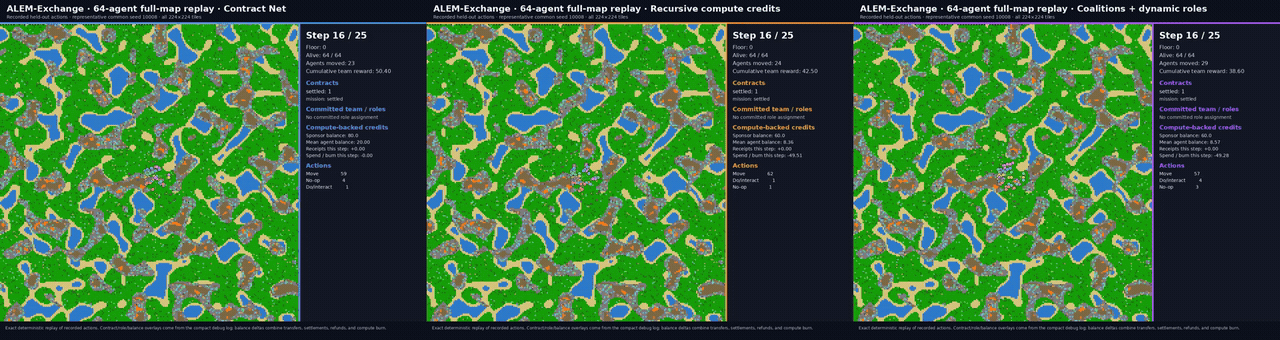
Coalition behavior in a deterministic multi-agent replay, seed 10008. The clip illustrates the coordination setting.
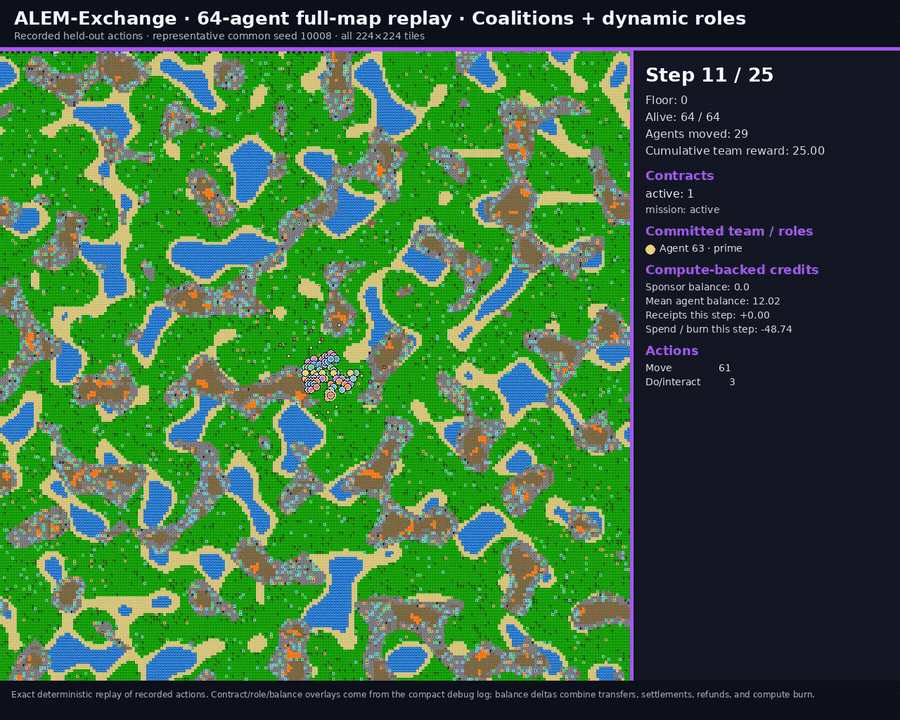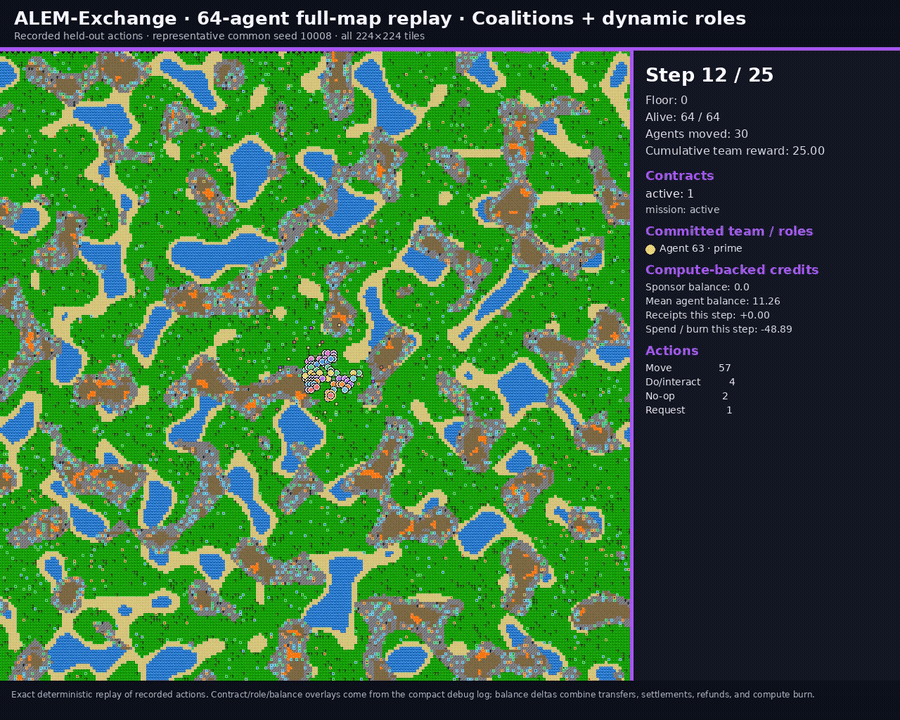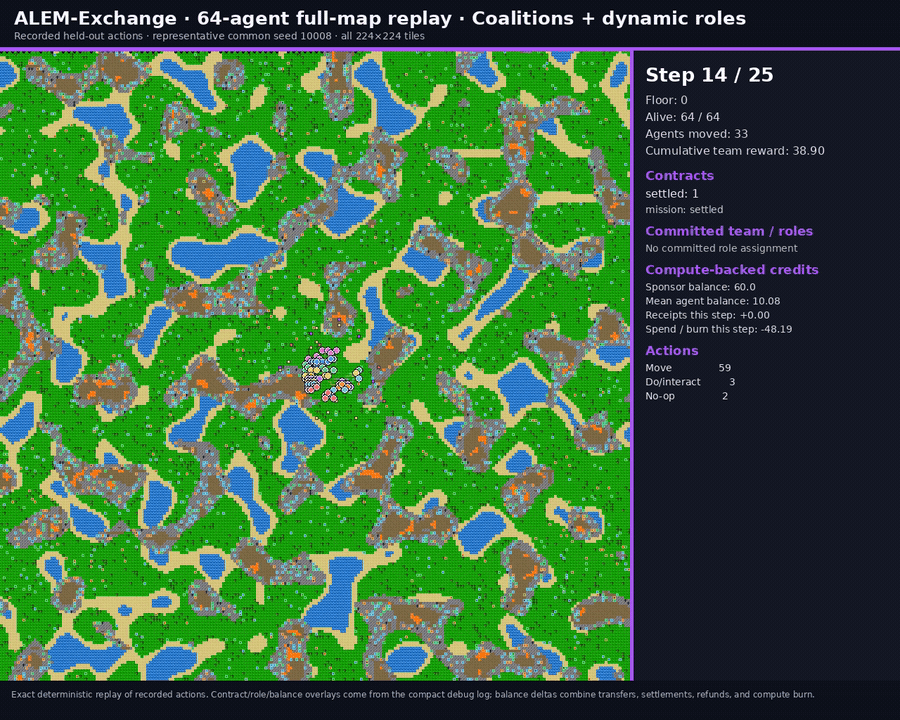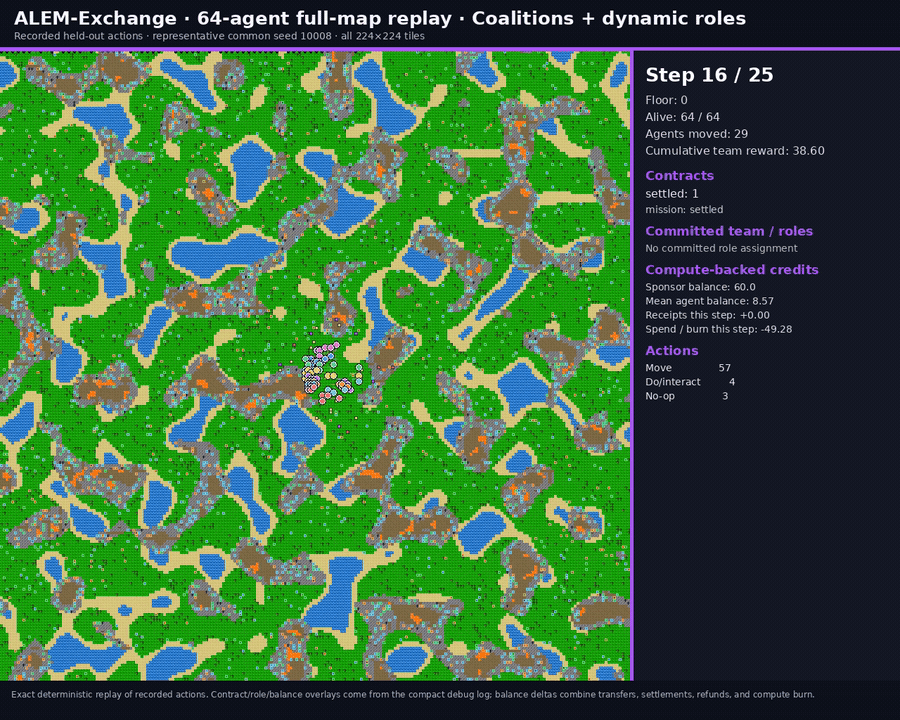

Comparing coordination strategies
Coordination methods shown side by side in the same simulated setting. The held-out study did not establish an efficiency advantage.
Sensor design

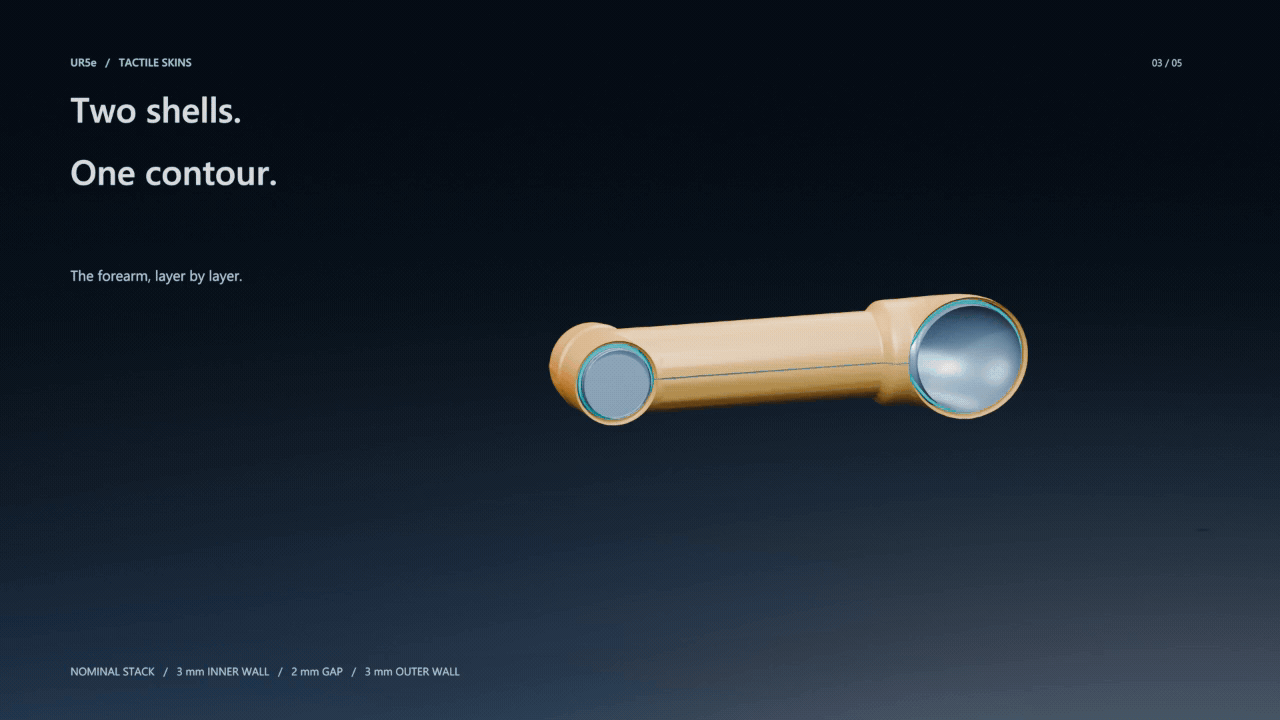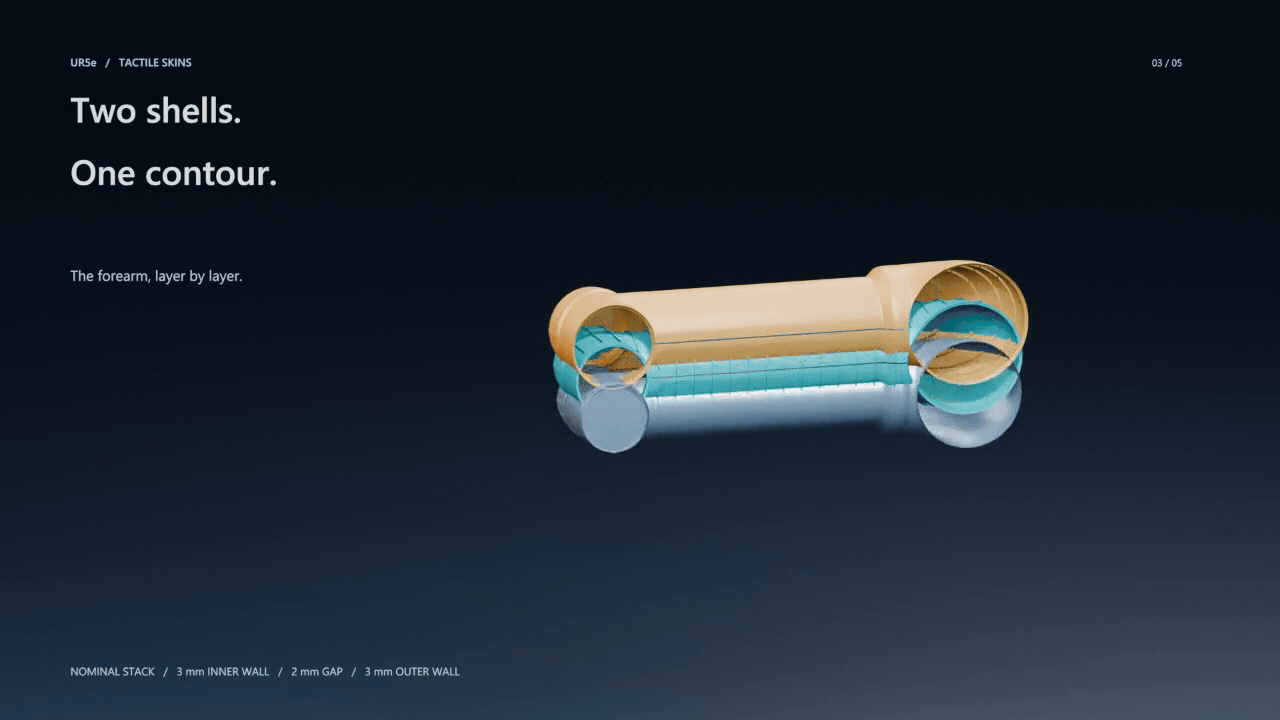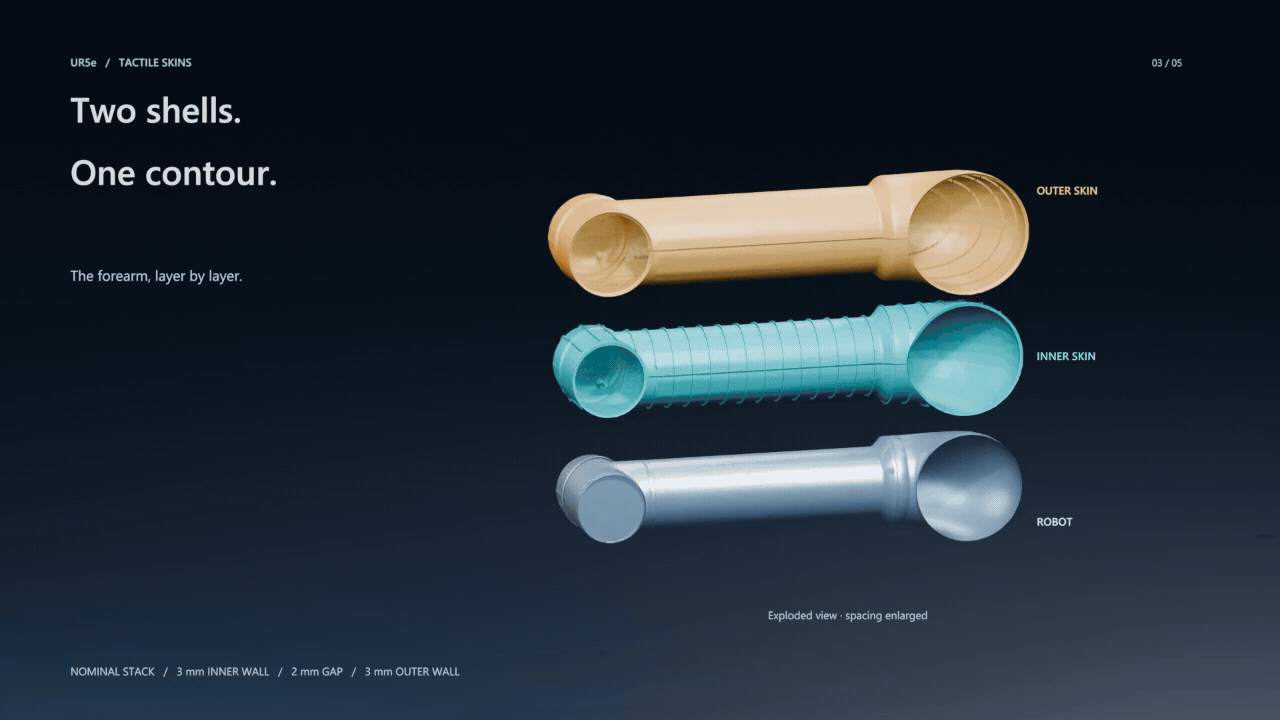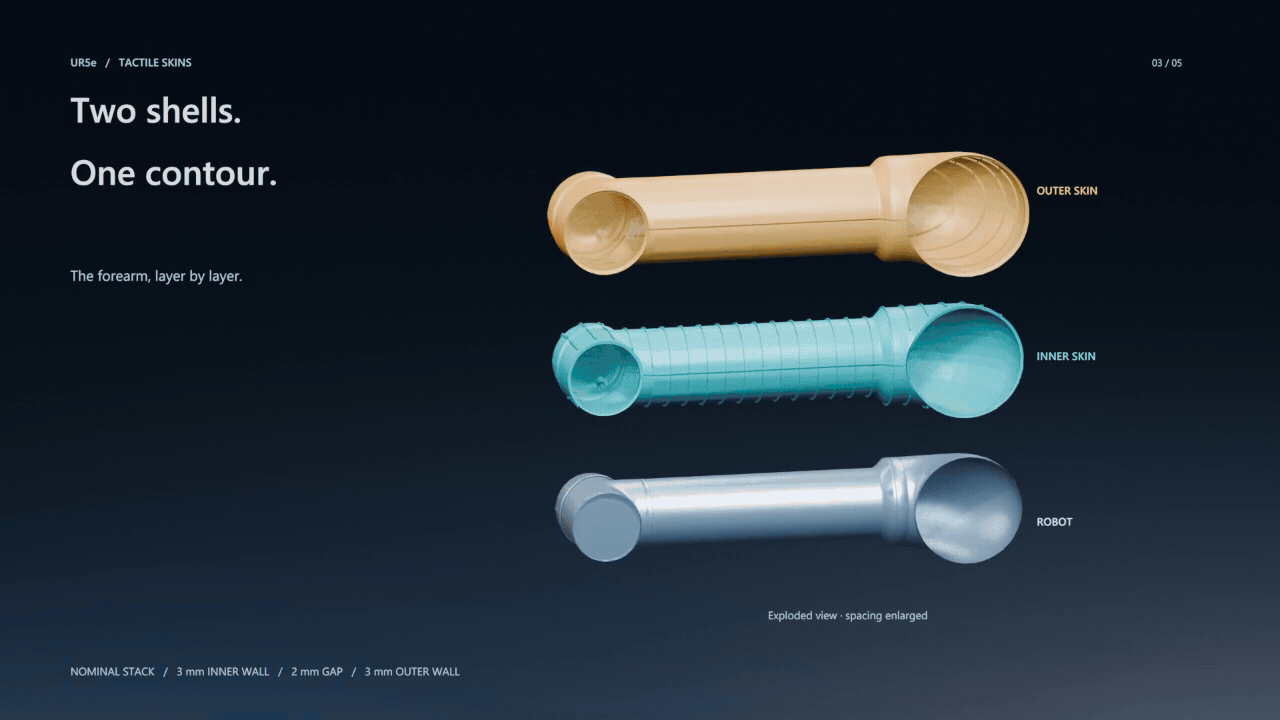
UR5e tactile-skin walkthrough
A 34-second walkthrough of the UR5e skin geometry. Physical fit through motion, fabrication, and sensing performance remain to be tested.
The page uses smaller animated images where supported, with real GIF files available for every preview. Animations load as you reach them; reduced-motion preferences start the page paused. Full-length recordings remain on the Videos page.