SPARK-Remote
An accessible remote bimanual teleoperation system for the RPM Lab's dual-arm platform (ICRA 2025 workshop).
Remote bimanual operation
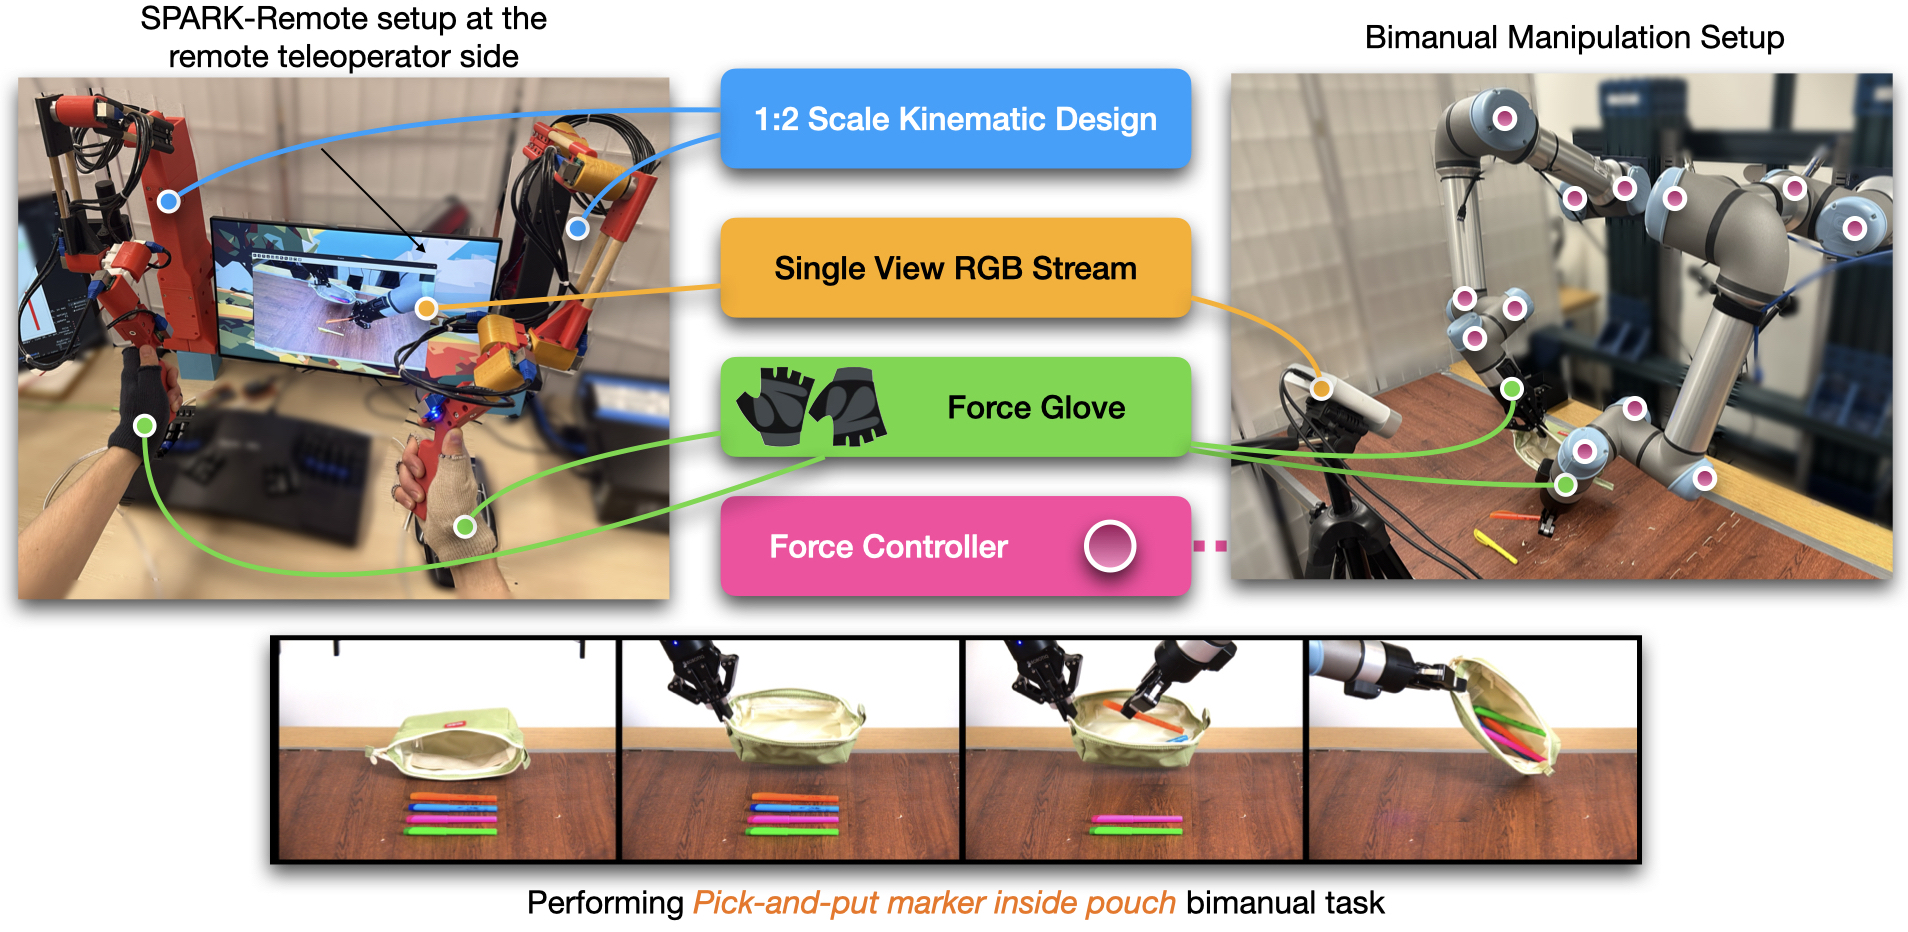
SPARK-Remote combines an accessible operator interface with the RPM Lab’s dual-arm platform. The project demonstrates teleoperation tasks and documents the interface in its public project site. I contributed to the system and the ICRA 2025 workshop publication.