Tactile Materials and Conformal Interfaces
Experimental sensor coupons and connected laminate patterns for surfaces that must bend around a robot.
Making sensing surfaces fit
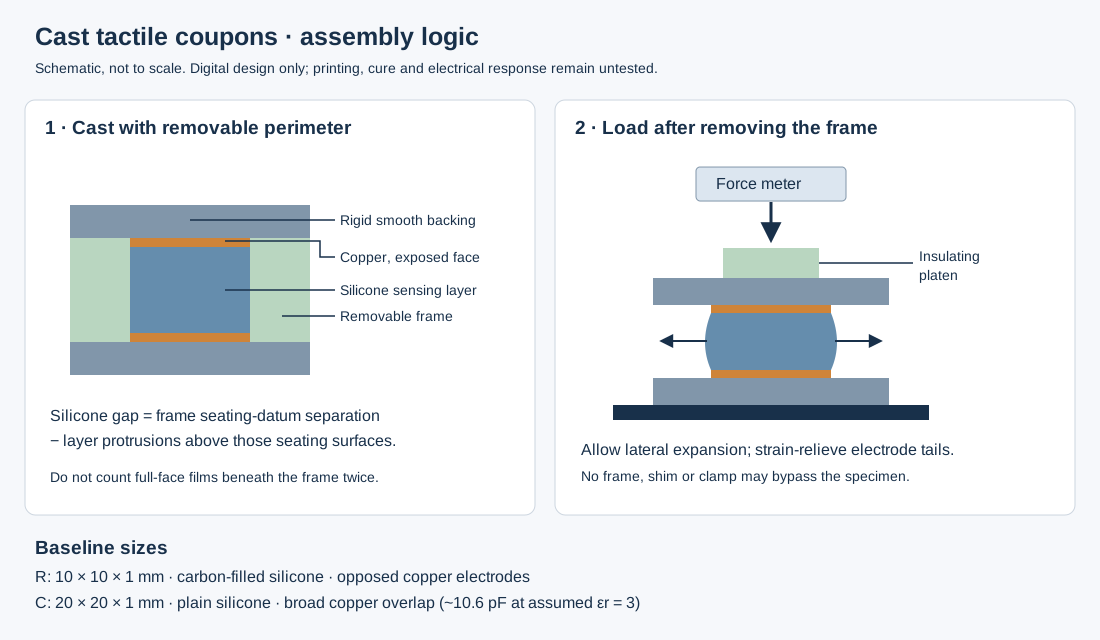
I prototype soft sensing materials and conformal layouts alongside the robot-scale tactile-skin work. Current studies include cast sensor coupons, electrical readout, and parametric auxetic laminate patterns that can stay connected while bending over curved surfaces.
The laminate designs have been checked as geometry and cutting files. Sensor measurements are early, local experiments; they are not calibrated force maps or proof of durability on a moving robot. The goal is to learn which materials and layouts can provide usable body contact signals at practical scale.
Design and fabrication views